
Public C API for reading PANGEA camera calibration profiles. More...
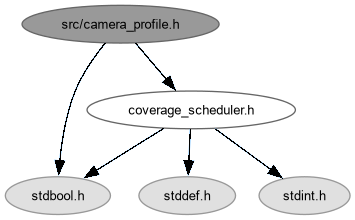
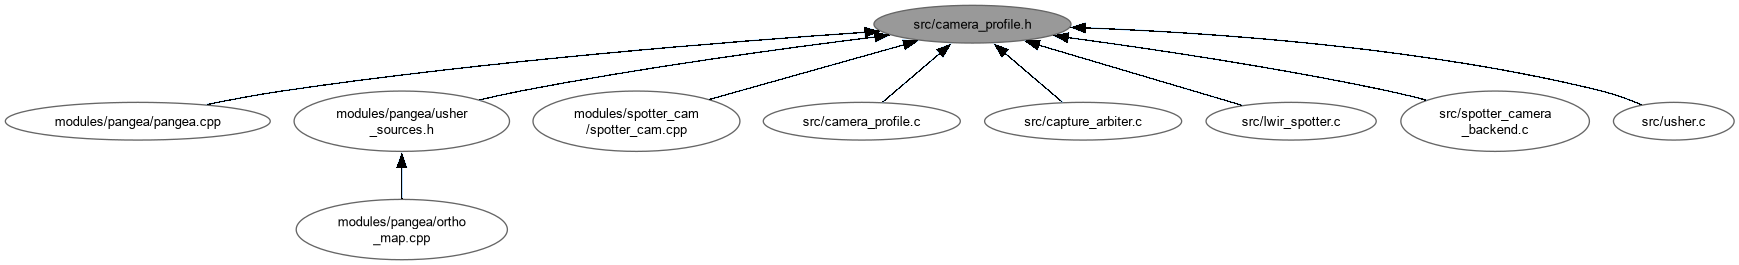
Go to the source code of this file.
Data Structures | |
| struct | usher_camera_profile |
| One measured camera calibration loaded from the flat PANGEA profile format. More... | |
Macros | |
| #define | CAMERA_PROFILE_MAX_BYTES 1024 |
Functions | |
| bool | usher_camera_profile_read (const char *filename, struct usher_camera_profile *profile) |
| Read a bounded PANGEA_CAMERA_V1 key=value calibration file. | |
Detailed Description
Public C API for reading PANGEA camera calibration profiles.
The file binds measured intrinsics and mount angles to a camera filename prefix so mapping geometry is never guessed from a backend ID.
Definition in file camera_profile.h.
Macro Definition Documentation
◆ CAMERA_PROFILE_MAX_BYTES
| #define CAMERA_PROFILE_MAX_BYTES 1024 |
Definition at line 30 of file camera_profile.h.
Function Documentation
◆ usher_camera_profile_read()
| bool usher_camera_profile_read | ( | const char * | filename, |
| struct usher_camera_profile * | profile ) |
Read a bounded PANGEA_CAMERA_V1 key=value calibration file.
- Parameters
-
[in] filename Profile path; comments and blank lines are allowed. [out] profile Receives parsed geometry and filename prefix; unchanged on failure.
- Returns
- True only when all required fields are present and valid.
No heap allocation is performed. Duplicate and unknown keys are rejected so a typo cannot silently select a different camera calibration. A valid mapping prefix may have no USHER camera ID (reported as zero); consumers also check that the calibration satisfies their geometry constraints.
Definition at line 132 of file camera_profile.c.