
Loading...
Searching...
No Matches
camera_projection.h File Reference
Map calibrated camera pixels to a local flat ground plane. More...
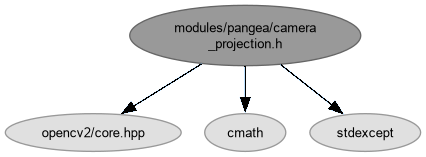
#include <opencv2/core.hpp>#include <cmath>#include <stdexcept>
Include dependency graph for camera_projection.h:
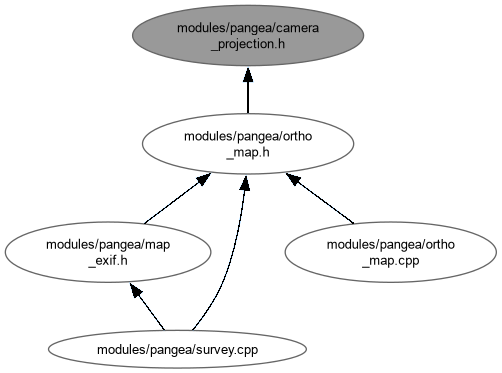
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| class | pangea_survey::CameraPlane |
Namespaces | |
| namespace | pangea_survey |
Functions | |
| cv::Matx33d | pangea_survey::cameraRotation (double roll, double pitch, double yaw) |
| Compose body attitude into the local camera-ray coordinate frame. | |
Detailed Description
Map calibrated camera pixels to a local flat ground plane.
Body and mount rotations are composed before the pinhole ray model. The cached inverse is reused across output pixels; invalid or horizon-facing rays are rejected rather than extrapolated into plausible-looking map points.
Definition in file camera_projection.h.