
Standalone, backend-neutral still-camera throughput benchmark. More...
#include <signal.h>#include <stdbool.h>#include <stddef.h>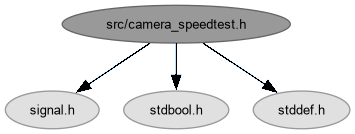
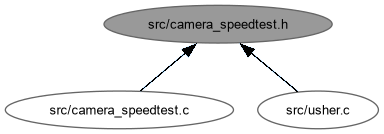
Go to the source code of this file.
Data Structures | |
| struct | camera_speedtest_config |
| Immutable dependencies for one selected and initialized camera backend. More... | |
Macros | |
| #define | CAMERA_SPEEDTEST_SAMPLE_COUNT 10 |
| #define | CAMERA_SPEEDTEST_FIRST_IMAGE 900000 |
| #define | CAMERA_SPEEDTEST_LAST_IMAGE 999999 |
Functions | |
| int | camera_speedtest_create_output_directory (const char *base_directory, char *output, size_t output_size) |
| Atomically create a private directory for one benchmark run. | |
| int | camera_speedtest_find_image_block (const struct camera_speedtest_config *config, int *first_image) |
| Find an unused consecutive image-number block for warm-up and samples. | |
| int | camera_speedtest_run (const struct camera_speedtest_config *config, int first_image) |
| Capture one untimed warm-up image and ten timed images sequentially. | |
Detailed Description
Standalone, backend-neutral still-camera throughput benchmark.
Definition in file camera_speedtest.h.
Macro Definition Documentation
◆ CAMERA_SPEEDTEST_FIRST_IMAGE
| #define CAMERA_SPEEDTEST_FIRST_IMAGE 900000 |
Definition at line 31 of file camera_speedtest.h.
◆ CAMERA_SPEEDTEST_LAST_IMAGE
| #define CAMERA_SPEEDTEST_LAST_IMAGE 999999 |
Definition at line 32 of file camera_speedtest.h.
◆ CAMERA_SPEEDTEST_SAMPLE_COUNT
| #define CAMERA_SPEEDTEST_SAMPLE_COUNT 10 |
Definition at line 30 of file camera_speedtest.h.
Function Documentation
◆ camera_speedtest_create_output_directory()
| int camera_speedtest_create_output_directory | ( | const char * | base_directory, |
| char * | output, | ||
| size_t | output_size ) |
Atomically create a private directory for one benchmark run.
- Parameters
-
base_directory Configured backend photo root. output Receives the new directory path. output_size Capacity of output.
- Returns
- 0 on success, otherwise -1 with errno set.
A private mode-0700 directory prevents benchmark backends, which normally replace same-number files, from racing with or overwriting mission photographs.
Definition at line 117 of file camera_speedtest.c.
◆ camera_speedtest_find_image_block()
| int camera_speedtest_find_image_block | ( | const struct camera_speedtest_config * | config, |
| int * | first_image ) |
Find an unused consecutive image-number block for warm-up and samples.
- Parameters
-
config Backend filename information. first_image Receives the warm-up image number.
- Returns
- 0 on success, -1 on invalid input, filesystem error, or exhausted range.
USHER camera backends replace an existing same-number image. Preflighting the complete block before camera initialization keeps benchmark evidence separate from mission captures and prevents accidental replacement of an existing photo.
Definition at line 404 of file camera_speedtest.c.
◆ camera_speedtest_run()
| int camera_speedtest_run | ( | const struct camera_speedtest_config * | config, |
| int | first_image ) |
Capture one untimed warm-up image and ten timed images sequentially.
- Parameters
-
config Selected and initialized camera backend. first_image Warm-up image number returned by camera_speedtest_find_image_block().
- Returns
- 0 only when every requested image was captured and validated.
Only synchronous shoot time is used for camera throughput. Progress records are written through bounded nonblocking I/O by a separate reporter thread, so a slow terminal cannot delay capture requests or inflate measured camera latency. Images are retained for review.
Definition at line 438 of file camera_speedtest.c.