
Loading...
Searching...
No Matches
dipla_gp_belief_planner.hpp File Reference
Native finite-grid GP sensor model and trajectory-planning API. More...
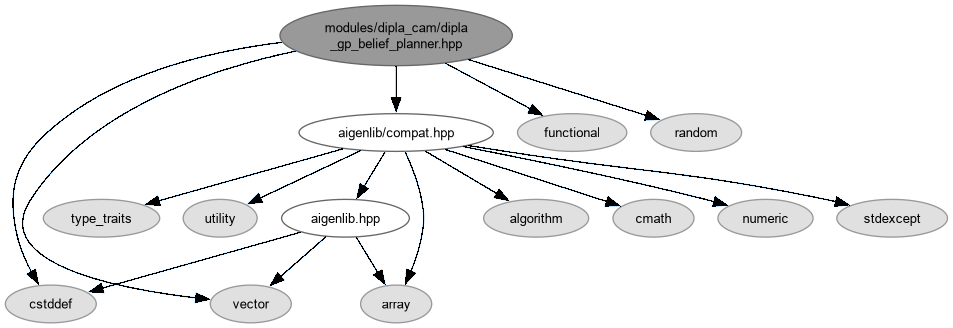
#include "aigenlib/compat.hpp"#include <cstddef>#include <functional>#include <random>#include <vector>
Include dependency graph for dipla_gp_belief_planner.hpp:
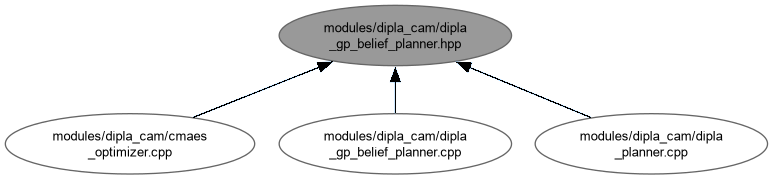
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | aipp::Grid |
| Rectangular, evenly spaced local map grid. More... | |
| struct | aipp::PlannerOptions |
| Search, utility, and optimizer controls for the reference planner. More... | |
Namespaces | |
| namespace | aipp |
Typedefs | |
| using | aipp::Matrix = math::Matrix |
| using | aipp::Vector = math::Vector |
| using | aipp::Point = math::Point |
| using | aipp::Sensor = dipla::aigenlib::Sensor |
| Sparse block-averaging observation operator. | |
Functions | |
| double | aipp::fov_radius (double altitude, double angle=60.0) |
| Compute the ground-plane footprint radius from altitude and full FOV angle. | |
| int | aipp::resolution_block_size (double altitude) |
| Select the research sensor's altitude-dependent aggregation block size. | |
| double | aipp::noise_model (double altitude, double minimum_altitude=10.0) |
| Compute modeled observation variance at an altitude. | |
| Matrix | aipp::initialize_covariance (const Grid &grid, double sigma2, double lengthscale) |
| Initialize a dense Matérn-3/2 GP covariance matrix. | |
| Sensor | aipp::build_sensor (const Grid &grid, const Point &pose, double angle=60.0, double observation_variance=-1.0) |
| Build one block-averaged sensor footprint at a pose. | |
| Sensor | aipp::future_sensor (const Grid &grid, const std::vector< Point > &path, double angle=60.0, int stride=lookahead_stride, int max_measurements=lookahead_measurement_budget, double observation_variance=-1.0) |
| Approximate future measurements along a path under a bounded budget. | |
| Vector | aipp::observe (const Sensor &sensor, const Vector &field) |
| Apply the sensor's block averages to a full-grid field. | |
| Vector | aipp::sample_sensor_noise (const Sensor &sensor, std::mt19937_64 &generator) |
| Draw independent zero-mean noise using each sensor row's variance. | |
| std::vector< bool > | aipp::importance_mask (const Vector &mean, const Matrix &covariance, const PlannerOptions &options) |
| Select cells whose confidence bounds satisfy the utility threshold. | |
| double | aipp::expected_reduction (const Matrix &covariance, const std::vector< bool > &mask, const Sensor &sensor) |
| Sum expected marginal-variance reduction over important cells. | |
| void | aipp::condition (Matrix &covariance, Vector *mean, const Sensor &sensor, const Vector *measurement) |
| Apply a Gaussian linear-observation update in place. | |
| Point | aipp::clip_point (const Grid &grid, const Point &point, const PlannerOptions &options) |
| Clamp a candidate to the map safety inset and altitude interval. | |
| std::vector< Point > | aipp::lattice (const Grid &grid, const PlannerOptions &options) |
| Generate the deduplicated coarse-to-fine candidate lattice. | |
| std::vector< Point > | aipp::spline (const Point &start, const std::vector< Point > &waypoints, int samples_per_segment=spline_samples_per_segment) |
| Interpolate controls with a natural cubic spline parameterized by distance. | |
| double | aipp::trajectory_objective (const Grid &grid, const Matrix &covariance, const std::vector< bool > &mask, const Point &start, const std::vector< Point > &raw_waypoints, const PlannerOptions &options) |
| Score a trajectory by safety violation and distance-normalized information gain. | |
| std::vector< Point > | aipp::grid_search (const Grid &grid, const Vector &mean, const Matrix &covariance, const Point &start, const PlannerOptions &options) |
| Greedily select a bounded route by information gain per travel cost. | |
| std::vector< Point > | aipp::refine (const Grid &grid, const Vector &mean, const Matrix &covariance, const Point &start, const std::vector< Point > &initial, const PlannerOptions &options) |
| Refine a greedy route with bounded CMA-ES while retaining its best candidate. | |
| std::vector< Point > | aipp::plan (const Grid &grid, const Vector &mean, const Matrix &covariance, const Point &start, const PlannerOptions &options) |
| Run greedy route selection followed by optional CMA-ES refinement. | |
Variables | |
| constexpr int | aipp::lookahead_stride = 4 |
| constexpr int | aipp::lookahead_measurement_budget = 64 |
| constexpr int | aipp::spline_samples_per_segment = 5 |
Detailed Description
Native finite-grid GP sensor model and trajectory-planning API.
Provides the reusable research/reference planner used by the explicitly selected CMA-ES comparison mode. The implementation stores dense covariance in build-selected row-major matrices, so the 2601-cell cap is a deliberate memory bound rather than an arbitrary input restriction.
Definition in file dipla_gp_belief_planner.hpp.