
Loading...
Searching...
No Matches
dipla_planner.hpp File Reference
Public planning, synthetic-survey, and comparison APIs for Diplacam. More...
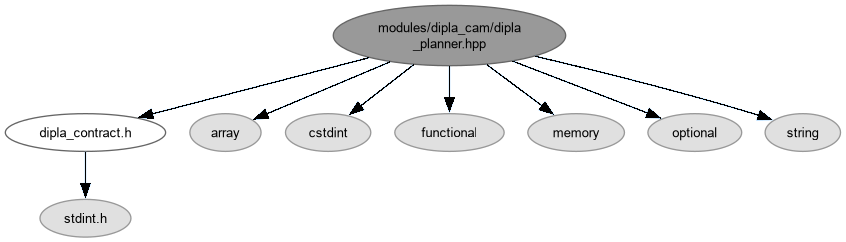
#include "dipla_contract.h"#include <array>#include <cstdint>#include <functional>#include <memory>#include <optional>#include <string>
Include dependency graph for dipla_planner.hpp:
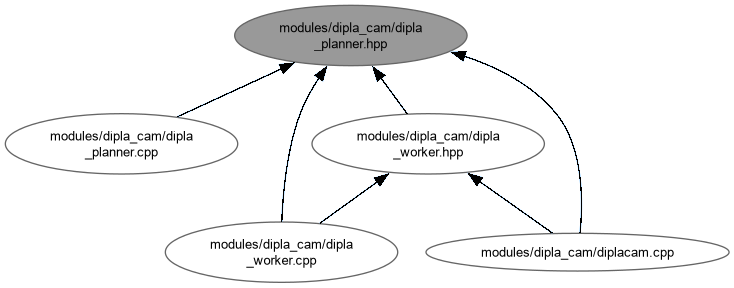
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | dipla::ExperimentOptions |
| Startup-only synthetic experiment settings shared by both planners. More... | |
| struct | dipla::Belief |
| Fixed-shape posterior summary consumed by the diffusion model. More... | |
| struct | dipla::CmaesOptions |
| Bounded parameters for the comparison-only CMA-ES planner. More... | |
| struct | dipla::NetworkOptions |
| Model identity and execution limits for a diffusion network. More... | |
| class | dipla::Network |
| Owns an ONNX session and samples eight metre-valued control points. More... | |
| class | dipla::Survey |
| Maintains a synthetic field, GP posterior, and planning comparisons. More... | |
Namespaces | |
| namespace | dipla |
Typedefs | |
| using | dipla::Noise = std::array<double, DIPLA_COORDINATE_COUNT * points> |
| using | dipla::Waypoints = std::array<std::array<double, DIPLA_COORDINATE_COUNT>, points> |
Functions | |
| void | dipla::apply_flight_margin (Waypoints &route, unsigned margin_cells=ExperimentOptions::default_margin_cells) |
| Apply the configured horizontal flight margin. | |
| void | dipla::initialize_runtime (const std::string &onnx_lib_path={}) |
| Load the ONNX Runtime C API before constructing an inference session. | |
Variables | |
| constexpr std::size_t | dipla::cells = DIPLA_GRID_SIDE * DIPLA_GRID_SIDE |
| constexpr std::size_t | dipla::points = DIPLA_WAYPOINT_COUNT |
Detailed Description
Public planning, synthetic-survey, and comparison APIs for Diplacam.
The production path conditions a finite-grid Gaussian-process belief from synthetic observations and samples eight waypoints with a native DDIM loop backed by ONNX Runtime. The opt-in comparison path plans over the same belief with the native greedy/CMA-ES reference; it is not an automatic fallback. Coordinates are local east/north metres. This header intentionally exposes fixed-size production contracts while hiding Eigen, ONNX Runtime, and planner implementation state from callers.
Definition in file dipla_planner.hpp.