
Sensor-independent acoustic samples and ground-source estimates. More...
#include <stdbool.h>#include <stddef.h>#include <stdint.h>
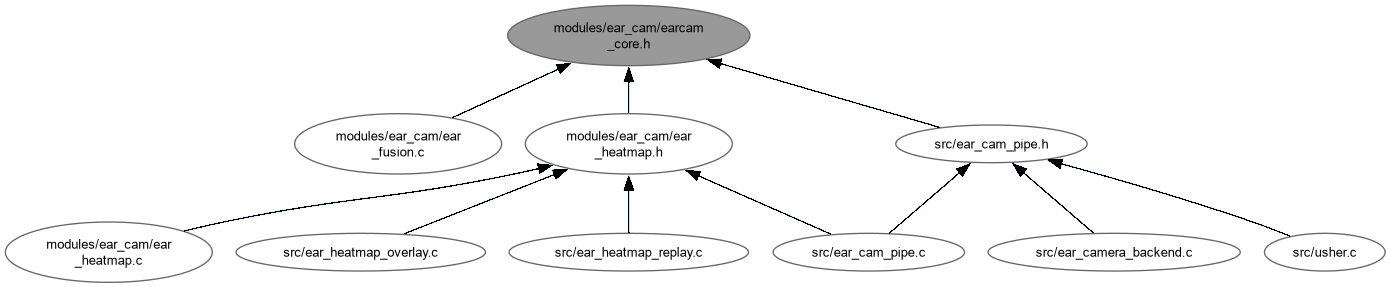
Go to the source code of this file.
Data Structures | |
| struct | ear_loudest_spot |
| Estimated ground source, not a surveyed target or guaranteed alarm detection. More... | |
| struct | ear_sample |
| One audio window associated with microphone position and provenance. More... | |
Macros | |
| #define | EAR_MAX_SAMPLES 16384U |
Functions | |
| int | calculated_loudestspot (const struct ear_sample *samples, size_t count, struct ear_loudest_spot *result) |
| Estimate a ground source from relative loudness along a survey track. | |
Detailed Description
Sensor-independent acoustic samples and ground-source estimates.
Supply geotagged audio windows from any capture adapter. This API does not acquire audio, own a flight session, or know about USHER/UART. Positions and heights must use a consistent navigation reference; the solver cannot repair microphone gain changes, unsynchronized poses or bad terrain data.
Definition in file earcam_core.h.
Macro Definition Documentation
◆ EAR_MAX_SAMPLES
| #define EAR_MAX_SAMPLES 16384U |
Bounded solver capacity; USHER reserves sample storage separately from this workspace.
Definition at line 34 of file earcam_core.h.
Function Documentation
◆ calculated_loudestspot()
| int calculated_loudestspot | ( | const struct ear_sample * | samples, |
| size_t | count, | ||
| struct ear_loudest_spot * | result ) |
Estimate a ground source from relative loudness along a survey track.
- Parameters
-
samples Caller-owned immutable windows; never modified or retained. count Input count, bounded by EAR_MAX_SAMPLES. result Required destination; cleared before validation when non-NULL.
- Returns
- Zero for an estimate, -1 for invalid input or insufficient retained evidence.
A robust centroid seeds a damped inverse-distance fit; unstable fits fall back to that centroid. Shared bounded scratch storage is mutex-protected, so concurrent calls serialize without allocating another survey-sized buffer.
- Warning
- A valid result is not an absolute alarm gate. With too few alarm windows the solver deliberately uses other finite levels, even silent ones. Mission policy must consider level, quality, geometry and independent evidence. The legacy near-zero-latitude placeholder gate also excludes equatorial tracks.
Definition at line 129 of file ear_fusion.c.