
Local-simulation JPEG attitude transform API. More...
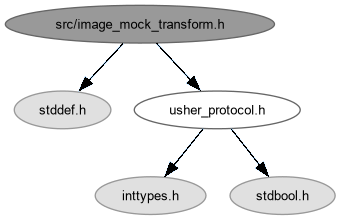
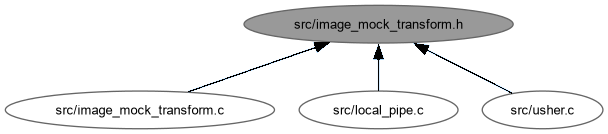
Go to the source code of this file.
Macros | |
| #define | IMAGE_MOCK_TRANSFORM_APPLIED 0 |
| Successful result: the JPEG was rewritten with the simulated attitude transform. | |
| #define | IMAGE_MOCK_TRANSFORM_SKIPPED 1 |
| Successful result: transform was intentionally skipped for a near-horizon attitude. | |
Functions | |
| int | image_mock_transform (const char *filename, const union dc_shot_union *shot) |
| Rewrite a local test JPEG to simulate the shot attitude. | |
| int | image_mock_map (const char *filename, const char *cache_directory, const union dc_shot_union *shot, size_t width, size_t height, double horizontal_fov_deg, double vertical_fov_deg) |
| Render a map-backed simulated exposure. | |
Detailed Description
Local-simulation JPEG attitude transform API.
Definition in file image_mock_transform.h.
Macro Definition Documentation
◆ IMAGE_MOCK_TRANSFORM_APPLIED
| #define IMAGE_MOCK_TRANSFORM_APPLIED 0 |
Successful result: the JPEG was rewritten with the simulated attitude transform.
Definition at line 28 of file image_mock_transform.h.
◆ IMAGE_MOCK_TRANSFORM_SKIPPED
| #define IMAGE_MOCK_TRANSFORM_SKIPPED 1 |
Successful result: transform was intentionally skipped for a near-horizon attitude.
Definition at line 30 of file image_mock_transform.h.
Function Documentation
◆ image_mock_map()
| int image_mock_map | ( | const char * | filename, |
| const char * | cache_directory, | ||
| const union dc_shot_union * | shot, | ||
| size_t | width, | ||
| size_t | height, | ||
| double | horizontal_fov_deg, | ||
| double | vertical_fov_deg ) |
Render a map-backed simulated exposure.
- Parameters
-
filename Destination JPEG path. cache_directory Local map tile cache root. shot Trigger containing position, attitude and AGL. width Output columns. height Output rows. horizontal_fov_deg Horizontal field of view in degrees. vertical_fov_deg Vertical field of view in degrees.
- Returns
- Zero on publication, or -1 on lock, geometry, cache, or I/O failure.
Serialize rendering with fixture transforms because both reuse the same codec and pixel workspace.
Definition at line 186 of file image_mock_transform.c.
◆ image_mock_transform()
| int image_mock_transform | ( | const char * | filename, |
| const union dc_shot_union * | shot ) |
Rewrite a local test JPEG to simulate the shot attitude.
- Parameters
-
filename Writable path to the JPEG to transform in place. shot Flight pose containing fixed-point roll, pitch, yaw, and position fields.
- Returns
IMAGE_MOCK_TRANSFORM_APPLIED,IMAGE_MOCK_TRANSFORM_SKIPPED, or -1 on failure.
The transform uses a perspective projection and an atomic temporary-file rename so consumers never observe a partial JPEG. Near-horizon frames are skipped or synthesized by configured policy because planar image projection becomes numerically untrustworthy there.
- Warning
- This is simulation evidence only; it does not model a calibrated physical camera.
Definition at line 346 of file image_mock_transform.c.