
Loading...
Searching...
No Matches
imx500_camera.hpp File Reference
Neutral IMX500 frame ownership, JPEG publication and worker protocol. More...
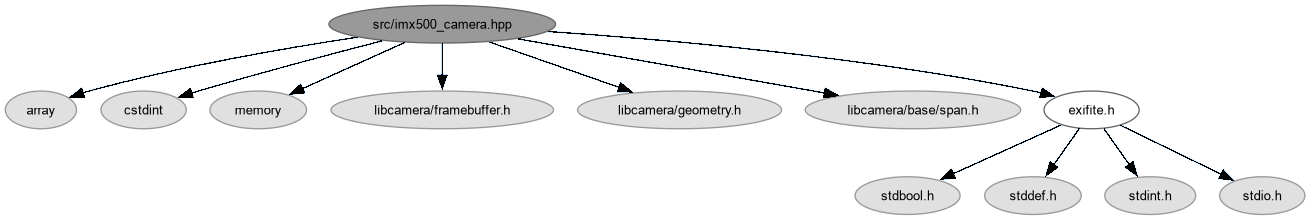
#include <array>#include <cstdint>#include <memory>#include <libcamera/framebuffer.h>#include <libcamera/geometry.h>#include <libcamera/base/span.h>#include "exifite.h"
Include dependency graph for imx500_camera.hpp:
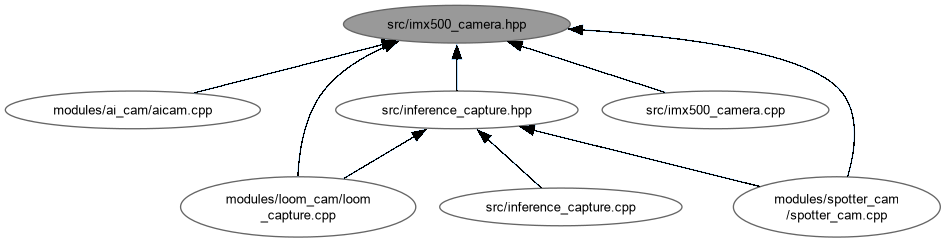
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | imx500::FrameView |
| Borrowed same-exposure evidence, without object or navigation semantics. More... | |
| struct | imx500::FrameProcessor |
| Stack-owned model-specific operations; no dynamic plugin allocation. More... | |
| class | imx500::FrameLease |
| Exactly-once release of a borrowed frame, including exception exits. More... | |
| class | imx500::Camera |
| One exclusive IMX500 owner with bounded reusable YUV420 buffers. More... | |
Namespaces | |
| namespace | imx500 |
| namespace | imx500::detail |
Enumerations | |
| enum class | imx500::detail::FrameStatus { imx500::detail::ready , imx500::detail::startup , imx500::detail::failed } |
Functions | |
| constexpr FrameStatus | imx500::detail::frame_status (libcamera::FrameMetadata::Status status) |
| Map libcamera metadata to this worker's frame disposition. | |
| constexpr bool | imx500::valid_capture_dimensions (unsigned width, unsigned height) |
| Check that capture dimensions meet the worker's raster policy. | |
| bool | imx500::detail::photo_only_frame (const FrameView &frame) |
| Confirm that a frame carries no neural output. | |
| bool | imx500::encode_jpeg (const char *path, const std::array< const uint8_t *, 3 > &planes, unsigned width, unsigned height, unsigned stride) |
| Encode validated YUV420 planes directly, without full-frame RGB staging. | |
| bool | imx500::publish_frame (const FrameView &frame, const std::array< const uint8_t *, 3 > &planes, unsigned stride, const char *filename, const FrameProcessor &processor) |
| Publish caller-validated YUV420 planes and same-exposure evidence. | |
| int | imx500::run_worker (int argc, char **argv, const FrameProcessor &processor, const char *application) |
| Run the shared probe/capture/READY-SHOT-OK worker with supplied model policy. | |
| int | imx500::run_photo_worker (int argc, char **argv, const char *application) |
| Run photo-only probe, capture or serve without model loading or inference. | |
Variables | |
| constexpr unsigned | imx500::sensor_width = 4056 |
| Physical IMX500 array width, used to reject an unexpected sensor geometry. | |
| constexpr unsigned | imx500::sensor_height = 3040 |
| Physical IMX500 array height; model input dimensions are separate policy. | |
Detailed Description
Neutral IMX500 frame ownership, JPEG publication and worker protocol.
Model interpretation belongs to the caller. Tensor views are borrowed from one retained camera request and may not outlive its FrameLease.
Definition in file imx500_camera.hpp.