
Loading...
Searching...
No Matches
inference_capture.cpp File Reference
One-owner capture, model preparation and no-overwrite result publication. More...
#include "inference_capture.hpp"#include <cerrno>#include <cstdio>#include <cstring>#include <fcntl.h>#include <limits>#include <memory>#include <stdexcept>#include <string>#include <sys/stat.h>#include <unistd.h>
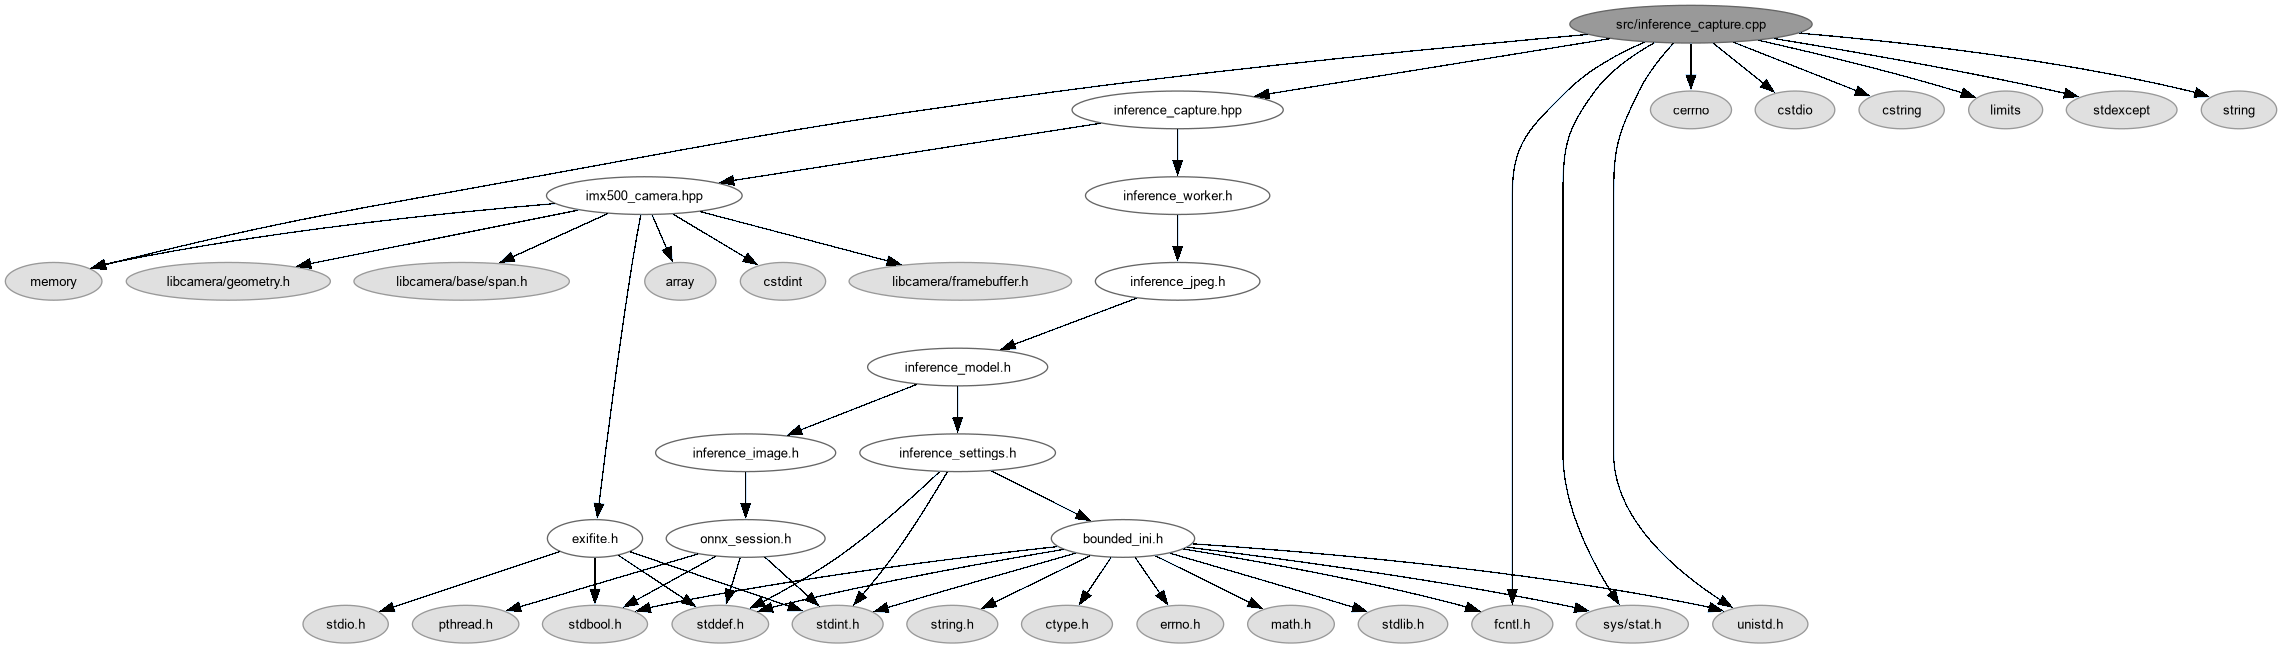
Include dependency graph for inference_capture.cpp:
Go to the source code of this file.
Functions | |
| int | inference_capture_cli (int argc, char **argv, const inference_image_processor &processor, const imx500::FrameProcessor &sensor_processor) |
| Dispatch configured RPK/ONNX capture while preserving one physical camera owner. | |
Detailed Description
One-owner capture, model preparation and no-overwrite result publication.
CPU inference runs after the frame lease ends so model latency does not hold camera DMA ownership.
Definition in file inference_capture.cpp.
Function Documentation
◆ inference_capture_cli()
| int inference_capture_cli | ( | int | argc, |
| char ** | argv, | ||
| const inference_image_processor & | processor, | ||
| const imx500::FrameProcessor & | sensor_processor ) |
Dispatch configured RPK/ONNX capture while preserving one physical camera owner.
- Parameters
-
argc Count of borrowed command-line arguments. argv Capture tokens; –settings - requests executable-relative discovery. processor CPU-model contract, output callbacks and application settings handler. sensor_processor Existing RPK feature/detection policy for the on-sensor backend.
- Returns
- Minus one for another CLI mode, zero on success, one on runtime failure, two on misuse.
Pixels are prepared and encoded under the frame lease; slow CPU inference follows release. Private image/result names are finalized before no-overwrite publication; failures never replay exposure.
Definition at line 110 of file inference_capture.cpp.