
LOOM executable entry point and neural-feature capture policy. More...
#include "../../src/version.h"#include "../../src/inference_worker.h"#include "../../src/image_exif.h"#include "loom_features.h"#include "loom_return.h"#include <cstdio>#include <cstring>#include <cmath>#include <unistd.h>#include <cerrno>#include <sys/stat.h>#include "../../src/imx500_camera.hpp"#include "../../src/inference_capture.hpp"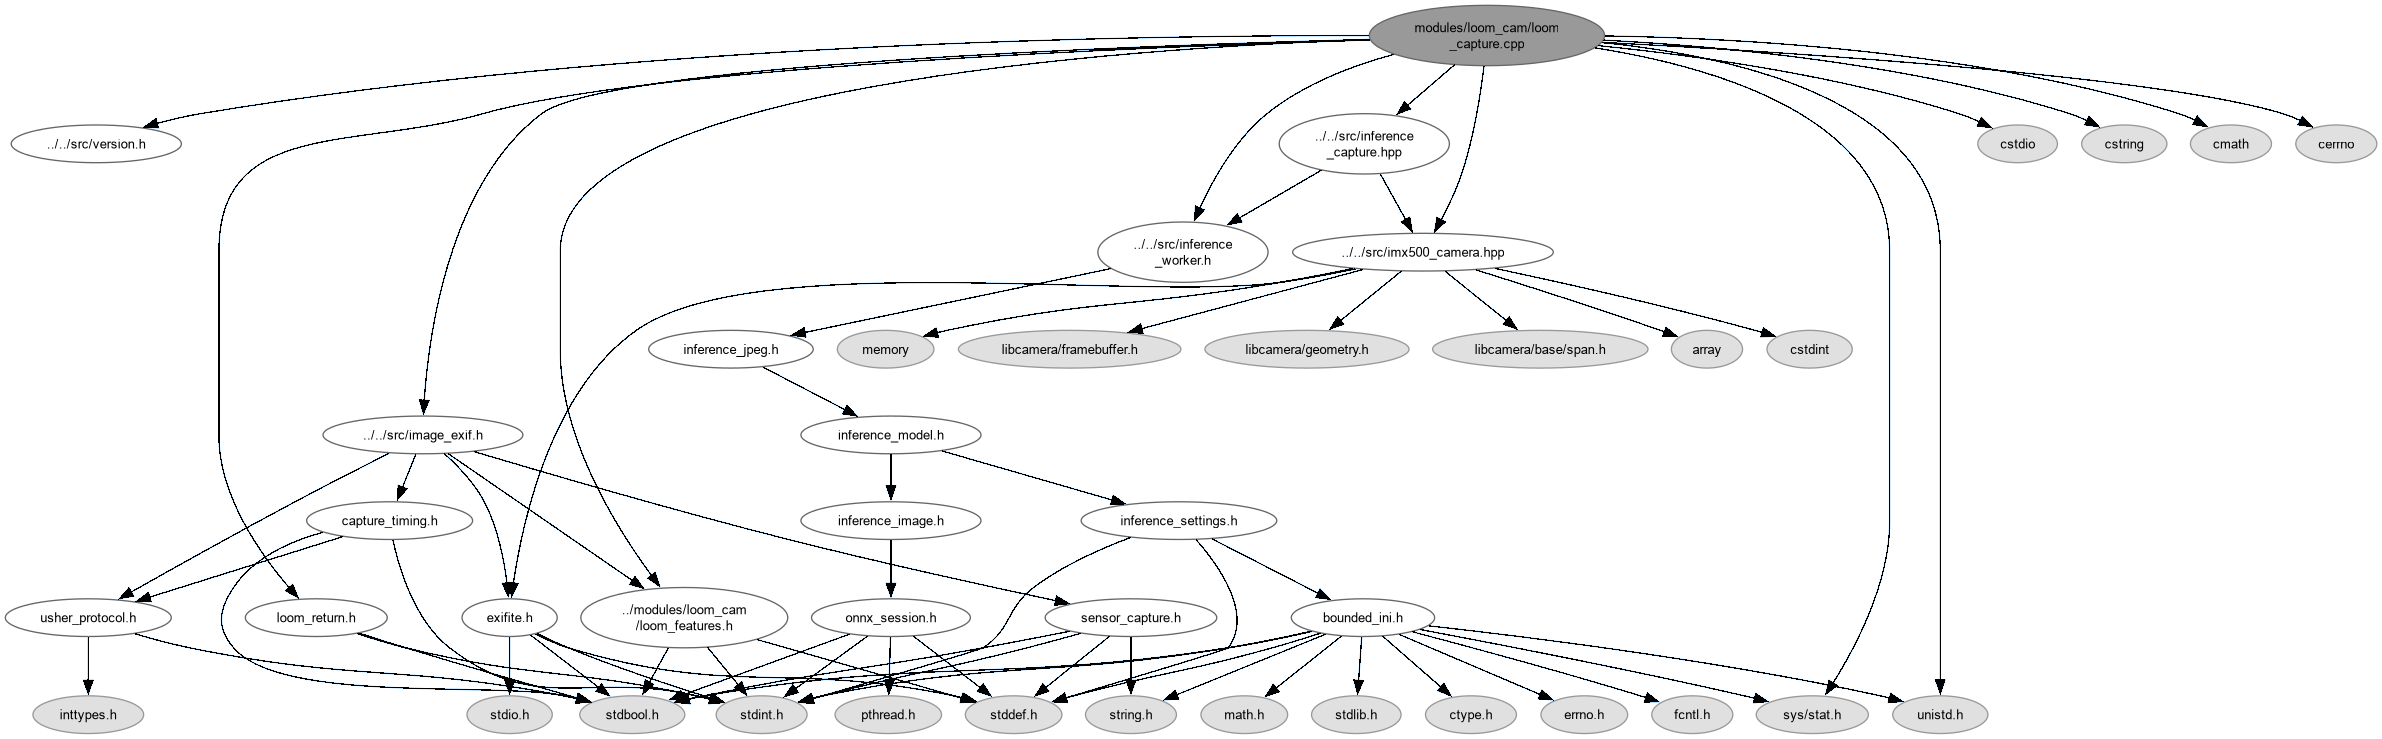
Go to the source code of this file.
Functions | |
| int | loomcam_photo_main (int argc, char **argv) |
| Dispatch the saved-photo CLI through its C linkage boundary. | |
| int | main (int argc, char **argv) |
| Dispatch saved-photo processing without opening a second camera owner. | |
Detailed Description
LOOM executable entry point and neural-feature capture policy.
Shared IMX500 mechanics know nothing about feature interpretation or waypoint selection. This application never calls the object-box decoder.
Definition in file loom_capture.cpp.
Function Documentation
◆ loomcam_photo_main()
| int loomcam_photo_main | ( | int | argc, |
| char ** | argv ) |
Dispatch the saved-photo CLI through its C linkage boundary.
- Parameters
-
argc Argument count including the command name. argv Arguments for the saved-photo path.
- Returns
- CLI exit status; successful processing may report no match.
This entry does not acquire a sensor. Keep the saved-photo CLI separate from the native capture worker.
◆ main()
| int main | ( | int | argc, |
| char ** | argv ) |
Dispatch saved-photo processing without opening a second camera owner.
- Parameters
-
argc Command-line token count. argv Saved-photo or neutral capture-worker mode arguments.
- Returns
- Zero for success, two for syntax errors, one for capture runtime failure.
Capture retains features; saved-photo mode validates declared return vectors and observation identity. Generic tensors are not navigation evidence.
Definition at line 202 of file loom_capture.cpp.