
LOOM-owned bounded feature validation and evidence serialization. More...
#include <stdbool.h>#include <stddef.h>#include <stdint.h>
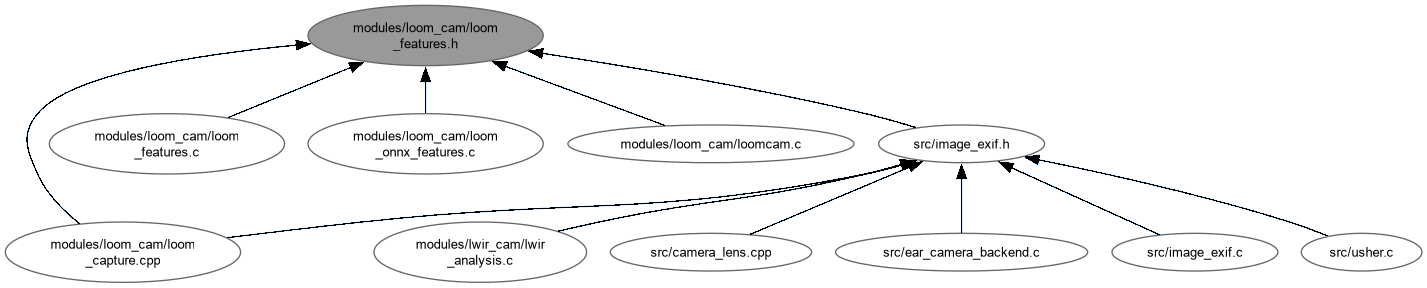
Go to the source code of this file.
Macros | |
| #define | LOOM_FEATURES_TAG 0xc7a2U |
| LOOM-owned camera-directory tag; its value is a LOOMNN02 opaque record. | |
| #define | LOOM_ONNX_FEATURES_TAG 0xc7a3U |
| #define | LOOM_ONNX_FEATURE_CAPACITY 32768U |
Functions | |
| bool | loom_features_valid (const float *values, size_t count, const uint8_t *information, size_t information_size) |
| Validate finite features against the shared IMX500 shape metadata. | |
| size_t | loom_features_size (size_t count) |
| Required bytes for 1..4096 floats, or zero for unsupported counts. | |
| bool | loom_features_pack (unsigned char *record, size_t capacity, const float *values, size_t count, const uint8_t *information, size_t information_size, uint64_t sequence, uint64_t sensor_timestamp_ns) |
| Pack validated same-exposure shapes, exact uint64 identities and float bits. | |
| bool | loom_features_unpack (const unsigned char *record, size_t size, float *values, size_t capacity, uint8_t *information, size_t information_size, size_t *count, uint64_t *sequence, uint64_t *sensor_timestamp_ns) |
| Validate and decode an exact-sized binary record into bounded output. | |
| size_t | loom_onnx_features_pack (unsigned char *record, size_t capacity, const struct inference_model *model, uint64_t sequence, uint64_t sensor_timestamp_ns) |
| Encode a complete LOOMOX01 record without fabricating an IMX500 metadata header. | |
| bool | loom_onnx_features_valid (const unsigned char *record, size_t size, const char *model_sha256, const char *descriptor_sha256) |
| Validate the exact binary layout and optionally require the same trained feature space. | |
| bool | loom_onnx_return_vector (const unsigned char *record, size_t size, const char *model_sha256, const char *descriptor_sha256, float values[3]) |
| Decode an explicitly declared two/three-value return-vector record. | |
Detailed Description
LOOM-owned bounded feature validation and evidence serialization.
Raw immutable buffers keep this core independent of libcamera and USHER process ownership. Valid feature transport is never navigation evidence.
Definition in file loom_features.h.
Macro Definition Documentation
◆ LOOM_FEATURES_TAG
| #define LOOM_FEATURES_TAG 0xc7a2U |
LOOM-owned camera-directory tag; its value is a LOOMNN02 opaque record.
Definition at line 30 of file loom_features.h.
◆ LOOM_ONNX_FEATURE_CAPACITY
| #define LOOM_ONNX_FEATURE_CAPACITY 32768U |
Definition at line 32 of file loom_features.h.
◆ LOOM_ONNX_FEATURES_TAG
| #define LOOM_ONNX_FEATURES_TAG 0xc7a3U |
Definition at line 31 of file loom_features.h.
Function Documentation
◆ loom_features_pack()
| bool loom_features_pack | ( | unsigned char * | record, |
| size_t | capacity, | ||
| const float * | values, | ||
| size_t | count, | ||
| const uint8_t * | information, | ||
| size_t | information_size, | ||
| uint64_t | sequence, | ||
| uint64_t | sensor_timestamp_ns ) |
Pack validated same-exposure shapes, exact uint64 identities and float bits.
- Precondition
- Inputs remain immutable and do not overlap the destination.
Writes the LOOMNN02 format described in docs/exif.md. Invalid inputs leave output unchanged. The caller reserves this value in the JPEG's EXIF document; there is no filesystem access or feature-sized allocation here.
Definition at line 116 of file loom_features.c.
◆ loom_features_size()
| size_t loom_features_size | ( | size_t | count | ) |
Required bytes for 1..4096 floats, or zero for unsupported counts.
Definition at line 100 of file loom_features.c.
◆ loom_features_unpack()
| bool loom_features_unpack | ( | const unsigned char * | record, |
| size_t | size, | ||
| float * | values, | ||
| size_t | capacity, | ||
| uint8_t * | information, | ||
| size_t | information_size, | ||
| size_t * | count, | ||
| uint64_t * | sequence, | ||
| uint64_t * | sensor_timestamp_ns ) |
Validate and decode an exact-sized binary record into bounded output.
- Precondition
- Inputs and writable outputs do not overlap; capacity is a float count.
On failure count is zero; other outputs must be discarded. Structural validity is not a model match. Check identity against the JPEG capture record before consuming features. No buffer is retained or allocated.
Definition at line 136 of file loom_features.c.
◆ loom_features_valid()
| bool loom_features_valid | ( | const float * | values, |
| size_t | count, | ||
| const uint8_t * | information, | ||
| size_t | information_size ) |
Validate finite features against the shared IMX500 shape metadata.
- Parameters
-
values Borrowed immutable float array for one exposure. count Accessible float count. information Borrowed tensor-info bytes from that same exposure. information_size Accessible metadata bytes.
- Returns
- True for bounded, consistent shapes and finite values; false otherwise.
Check shape products and cumulative length before reading values; rank/count limits bound both work and metadata access. No buffer is retained.
- Note
- This does not validate model semantics, feature similarity or a route.
Definition at line 47 of file loom_features.c.
◆ loom_onnx_features_pack()
| size_t loom_onnx_features_pack | ( | unsigned char * | record, |
| size_t | capacity, | ||
| const struct inference_model * | model, | ||
| uint64_t | sequence, | ||
| uint64_t | sensor_timestamp_ns ) |
Encode a complete LOOMOX01 record without fabricating an IMX500 metadata header.
- Parameters
-
record Writable destination, unchanged when validation rejects the input. capacity Available bytes; records cannot exceed LOOM_ONNX_FEATURE_CAPACITY. model Completed immutable float outputs and their exact graph/descriptor identities. sequence Source correlation, retained separately from any flight-controller shot number. sensor_timestamp_ns Physical sensor time when available; zero explicitly means unavailable.
- Returns
- Encoded byte count, or zero for invalid/nonfinite/oversized features.
- Precondition
- Input tensors and destination do not overlap. This transport does not establish a visual match.
Definition at line 39 of file loom_onnx_features.c.
◆ loom_onnx_features_valid()
| bool loom_onnx_features_valid | ( | const unsigned char * | record, |
| size_t | size, | ||
| const char * | model_sha256, | ||
| const char * | descriptor_sha256 ) |
Validate the exact binary layout and optionally require the same trained feature space.
- Parameters
-
record Immutable LOOMOX01 bytes. size Exact record length; truncation and trailing bytes are rejected. model_sha256 Required graph digest, or NULL for structural validation only. descriptor_sha256 Required preprocessing digest, or NULL for structural validation only.
- Returns
- True for bounded finite features and matching supplied identities, not navigation validity.
Definition at line 102 of file loom_onnx_features.c.
◆ loom_onnx_return_vector()
| bool loom_onnx_return_vector | ( | const unsigned char * | record, |
| size_t | size, | ||
| const char * | model_sha256, | ||
| const char * | descriptor_sha256, | ||
| float | values[3] ) |
Decode an explicitly declared two/three-value return-vector record.
- Parameters
-
record Retained LOOMOX01 bytes from this JPEG. size Exact record length. model_sha256 Required graph identity, or NULL. descriptor_sha256 Required descriptor identity, or NULL. values Three floats: first component, second component, confidence.
- Returns
- False unless exactly one finite two/three-value tensor is present.
A two-value model has no confidence output; 1 then means valid computation, not a measured probability. Frame semantics remain caller-owned.
Definition at line 142 of file loom_onnx_features.c.