
Loading...
Searching...
No Matches
ortho_map.h File Reference
Describe the validated photo set and render projected map windows. More...
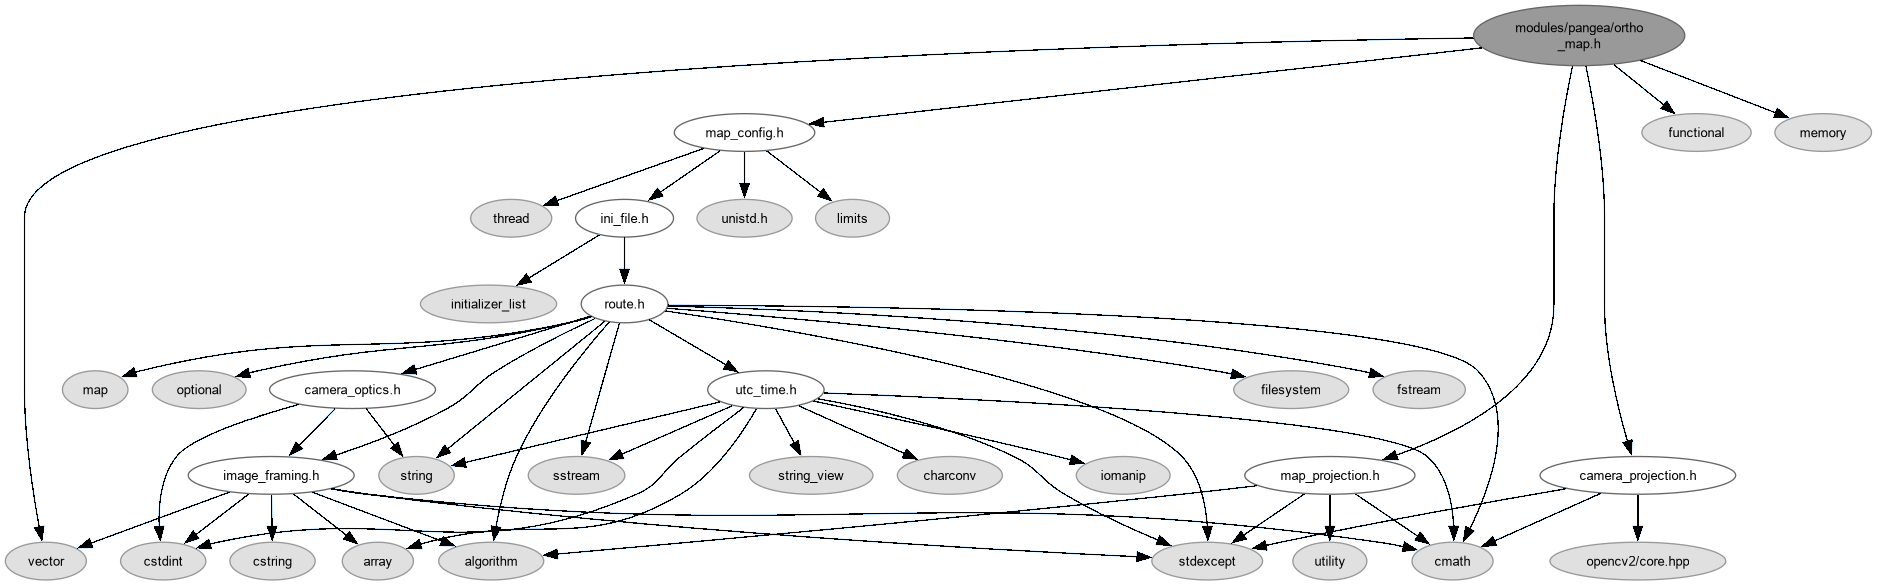
#include "map_config.h"#include "map_projection.h"#include "camera_projection.h"#include <functional>#include <memory>#include <vector>
Include dependency graph for ortho_map.h:
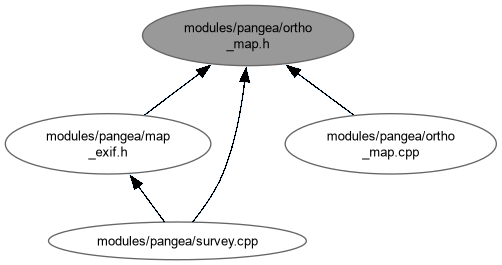
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | pangea_survey::OrthoLayout |
| UTM-aligned extent and tile count for one requested map area. More... | |
| struct | pangea_survey::OrthoSource |
| One fixed-session source image and its camera/pose evidence. More... | |
| struct | pangea_survey::OrthoImage |
| Rendered BGRA map plus coverage, source list, and method provenance. More... | |
| class | pangea_survey::Orthorectifier |
| Load a fixed-session source set and render its projected tiles/windows. More... | |
Namespaces | |
| namespace | pangea_survey |
Functions | |
| OrthoLayout | pangea_survey::orthoLayout (const MapConfig &config) |
| Compute a north-up, non-overlapping image grid for the requested bounds. | |
Detailed Description
Describe the validated photo set and render projected map windows.
Rendering retains source provenance and a per-pixel confidence class alongside colour so publication can distinguish observed colour from completion. The API keeps rendering separate from JPEG/XYZ publication, allowing both output formats to share the same map engine.
Definition in file ortho_map.h.