
Loading...
Searching...
No Matches
photo_exif.h File Reference
Encode simulated-camera pose, optics, and uncertainty into EXIF. More...
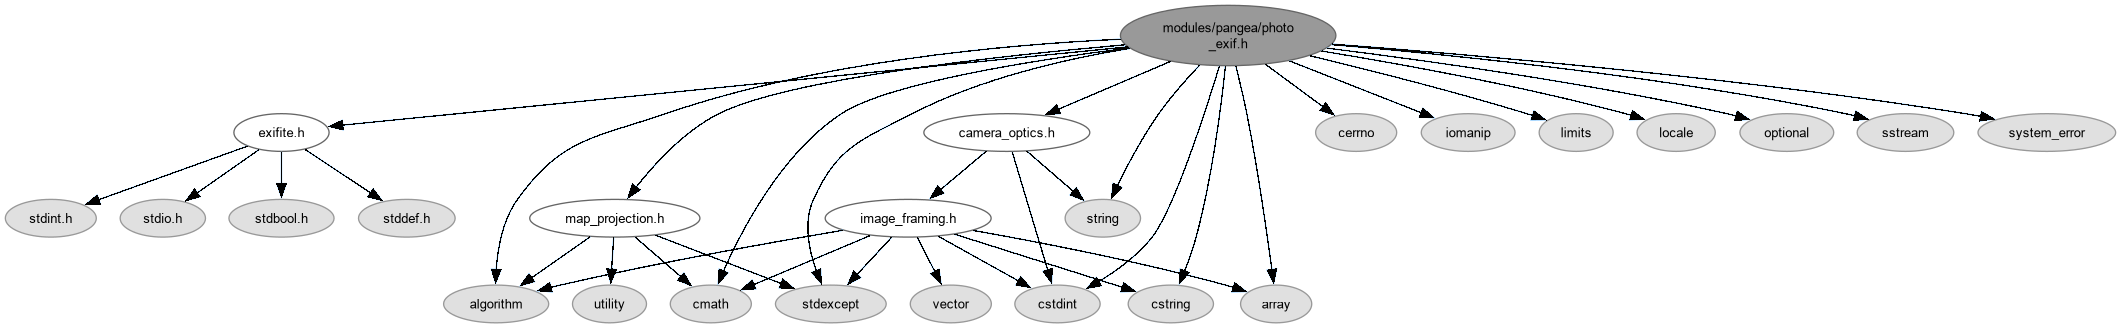
#include "exifite.h"#include "map_projection.h"#include "camera_optics.h"#include <algorithm>#include <array>#include <cerrno>#include <cmath>#include <cstdint>#include <cstring>#include <iomanip>#include <limits>#include <locale>#include <optional>#include <sstream>#include <stdexcept>#include <string>#include <system_error>
Include dependency graph for photo_exif.h:
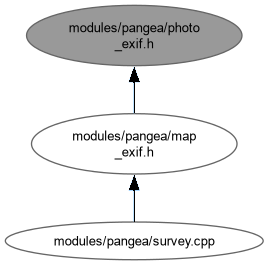
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Data Structures | |
| struct | pangea_survey::PhotoPosition |
| Photo location with AMSL camera and ground heights in metres. More... | |
| struct | pangea_survey::PhotoCamera |
| Camera and timing provenance required for a simulated-photo EXIF record. More... | |
| class | pangea_survey::PhotoExif |
| Build bounded EXIF payloads for simulator-generated source photos. More... | |
| struct | pangea_survey::PhotoExif::Payload |
| Borrowed serialized EXIF bytes held in this object's workspace. More... | |
Namespaces | |
| namespace | pangea_survey |
Detailed Description
Encode simulated-camera pose, optics, and uncertainty into EXIF.
Metadata distinguishes commanded pose from observed simulator pose, and labels nominal/emulated camera settings rather than presenting them as physical measurements. This is important because a complete EXIF record is provenance, not proof of exposure synchronization or surveyed accuracy.
Definition in file photo_exif.h.