Illustrated C/C++ source sheets, symbol index, API relationship graph, compiler console and debug trace

LIVE AI / FLEXIBLE SENSING / FLIGHT CONTEXT

Sensoraia API

Live AI and sensing, connected to the flight.
See, listen, inspect and return supported results while airborne.

Loading...
Searching...
No Matches
capture_job Struct Reference

Pool-owned worker request; ownership transfers only after thread creation succeeds. More...

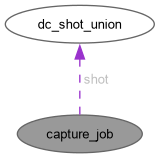
Collaboration diagram for capture_job:
Data Fields

union dc_shot_union shot
uint32_t request_id
uint8_t camera_mask
uint64_t ticket
uint64_t received_us
bool arbiter_owned
bool shot_counted

Detailed Description

Pool-owned worker request; ownership transfers only after thread creation succeeds.

Definition at line 250 of file usher.c.

Field Documentation

◆ arbiter_owned

bool capture_job::arbiter_owned

Protect admitted survey ownership from legacy newest-waiting replacement.

Definition at line 256 of file usher.c.

◆ camera_mask

uint8_t capture_job::camera_mask

Definition at line 253 of file usher.c.

◆ received_us

uint64_t capture_job::received_us

Local receipt time for queue age, never an exposure timestamp.

Definition at line 255 of file usher.c.

◆ request_id

uint32_t capture_job::request_id

Definition at line 252 of file usher.c.

◆ shot

union dc_shot_union capture_job::shot

Definition at line 251 of file usher.c.

◆ shot_counted

bool capture_job::shot_counted

Definition at line 257 of file usher.c.

◆ ticket

uint64_t capture_job::ticket

Optical ordering token, not a physical exposure sequence.

Definition at line 254 of file usher.c.


The documentation for this struct was generated from the following file: