
Private storage for the synthetic field and its GP posterior. More...
Public Member Functions | |
| State (const std::string &path, const ExperimentOptions &experiment) | |
| Load the complete synthetic lattice without inventing missing truth. | |
Data Fields | |
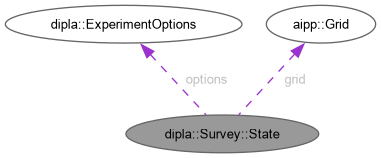
| const ExperimentOptions | options |
| aipp::Grid | grid {0.0, DIPLA_FIELD_EXTENT_M, 0.0, DIPLA_FIELD_EXTENT_M, DIPLA_GRID_STEP_M} |
| aipp::Matrix | covariance |
| aipp::Vector | mean |
| aipp::Vector | truth {aipp::Vector::Zero(cells)} |
| std::uint32_t | last_number = 0 |
| std::mt19937_64 | sensor_generator |
| std::uint64_t | digest = fnv_offset_basis |
Detailed Description
Private storage for the synthetic field and its GP posterior.
Keep truth beside the synthetic observation source, not in the network's inputs: the planner should learn through measurements, not peek at the answer sheet. The mean and full covariance evolve together in place.
- Invariant
- Only accepted increasing observation numbers advance replay state.
- Warning
- The covariance is dense. Additional copies are substantial allocations on MORA's shared 512 MB board, even when the public Belief stays small.
Definition at line 620 of file dipla_planner.cpp.
Constructor & Destructor Documentation
◆ State()
|
inlineexplicit |
Load the complete synthetic lattice without inventing missing truth.
Numeric rows outside the deployed even-coordinate grid are ignored after parsing. Selected cells must appear exactly once; silently averaging duplicates or filling holes would change the experiment.
- Parameters
-
[in] path CSV with complete coverage of the selected 51-by-51 grid. [in] experiment Immutable GP and synthetic sensor policy.
- Exceptions
-
std::exception For file-system, allocation, reading, or data-validation failures.
- Note
- The 2 MiB file and 256-character row limits bound accepted input, not the dense covariance or every transient allocation made by streams.
Definition at line 648 of file dipla_planner.cpp.
Field Documentation
◆ covariance
| aipp::Matrix dipla::Survey::State::covariance |
Dense prior/posterior covariance; one matrix is about 51.6 MiB.
Definition at line 626 of file dipla_planner.cpp.
◆ digest
| std::uint64_t dipla::Survey::State::digest = fnv_offset_basis |
FNV-1a over data-row bytes with LF separators; excludes the CSV header.
Definition at line 636 of file dipla_planner.cpp.
◆ grid
| aipp::Grid dipla::Survey::State::grid {0.0, DIPLA_FIELD_EXTENT_M, 0.0, DIPLA_FIELD_EXTENT_M, DIPLA_GRID_STEP_M} |
Fixed 51-by-51 grid geometry.
Definition at line 624 of file dipla_planner.cpp.
◆ last_number
| std::uint32_t dipla::Survey::State::last_number = 0 |
Highest accepted observation identifier.
Definition at line 632 of file dipla_planner.cpp.
◆ mean
| aipp::Vector dipla::Survey::State::mean |
Configured prior/posterior mean, independent of the comparison threshold.
Definition at line 628 of file dipla_planner.cpp.
◆ options
| const ExperimentOptions dipla::Survey::State::options |
Immutable validated experiment snapshot; never reloaded mid-survey.
Definition at line 622 of file dipla_planner.cpp.
◆ sensor_generator
| std::mt19937_64 dipla::Survey::State::sensor_generator |
Independent configured sensor stream, never advanced by diffusion sampling.
Definition at line 634 of file dipla_planner.cpp.
◆ truth
| aipp::Vector dipla::Survey::State::truth {aipp::Vector::Zero(cells)} |
Private synthetic ground truth used only by the observation operator.
Definition at line 630 of file dipla_planner.cpp.
The documentation for this struct was generated from the following file:
- modules/dipla_cam/dipla_planner.cpp