
Bounded camera policy; Tiny1C requires full 256x192 image and temperature planes. More...
#include <lwir_device.h>
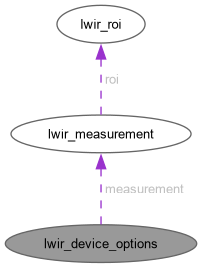
Data Fields | |
| const char * | serial |
| const char * | device_path |
| unsigned | width |
| unsigned | height |
| unsigned | warmup_ms |
| unsigned | timeout_ms |
| bool | scene_check |
| bool | settle |
| const struct lwir_measurement * | measurement |
| const volatile sig_atomic_t * | cancelled |
| enum lwir_frame_layout | layout |
| bool | requires_thermal |
Detailed Description
Bounded camera policy; Tiny1C requires full 256x192 image and temperature planes.
Zero dimensions select native geometry; Tiny1C's 256x192 image-only UVC mode is not combined data. The same structure is used for open and for each acquisition: open writes the negotiated geometry and layout back, and acquisition requires them to still match the session.
Definition at line 93 of file lwir_device.h.
Field Documentation
◆ cancelled
| const volatile sig_atomic_t* lwir_device_options::cancelled |
Borrowed cancellation flag; non-zero aborts waits with EINTR. NULL disables cancellation.
Definition at line 114 of file lwir_device.h.
◆ device_path
| const char* lwir_device_options::device_path |
Optional explicit V4L2 node (for example /dev/video2). NULL scans /dev/video0..63 and fails with EEXIST when more than one camera matches.
Definition at line 99 of file lwir_device.h.
◆ height
| unsigned lwir_device_options::height |
Definition at line 105 of file lwir_device.h.
◆ layout
| enum lwir_frame_layout lwir_device_options::layout |
Output of open: the detected camera's frame layout.
Definition at line 116 of file lwir_device.h.
◆ measurement
| const struct lwir_measurement* lwir_device_options::measurement |
Optional measurement region validated against the native geometry at open; NULL skips it.
Definition at line 112 of file lwir_device.h.
◆ requires_thermal
| bool lwir_device_options::requires_thermal |
Fail open with ENOTSUP when only an image-only camera is present.
Definition at line 118 of file lwir_device.h.
◆ scene_check
| bool lwir_device_options::scene_check |
scene_check: also require lwir_frame_plausible(); combined layout only, so enabling it for image-only sessions rejects every frame. settle: require consecutive frames to agree per lwir_frame_settled() before accepting, at the cost of at least one extra frame period.
Definition at line 110 of file lwir_device.h.
◆ serial
| const char* lwir_device_options::serial |
Optional USB serial string that must match exactly; NULL accepts any serial. Must fit in lwir_device::serial including its terminator.
Definition at line 96 of file lwir_device.h.
◆ settle
| bool lwir_device_options::settle |
Definition at line 110 of file lwir_device.h.
◆ timeout_ms
| unsigned lwir_device_options::timeout_ms |
Definition at line 105 of file lwir_device.h.
◆ warmup_ms
| unsigned lwir_device_options::warmup_ms |
Definition at line 105 of file lwir_device.h.
◆ width
| unsigned lwir_device_options::width |
width / height: per-plane native geometry, or zero for "native" before open; written on open success. warmup_ms: extra delay after the request starts, applied only on the first startup of a USB power instance; must be below timeout_ms. timeout_ms: whole-call budget in milliseconds, 1..120000.
Definition at line 105 of file lwir_device.h.
The documentation for this struct was generated from the following file:
- modules/lwir_cam/lwir_device.h