Loading...
Searching...
No Matches
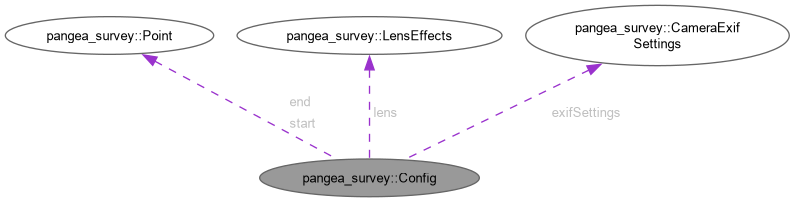
Validated camera, route, simulator-startup, and output settings.
More...
#include <route.h>
|
| bool | timedPhotoDue (double elapsed, double nextPhoto) const |
| | Check whether an enabled timed capture has reached its deadline.
|
| double | cameraFov () const |
| | Compute field of view at the selected map-camera height.
|
| double | cameraAgl (double nominalAgl) const |
| | Resolve the camera's height above ground.
|
| bool | piCamera () const |
| | Check for the calibrated Raspberry Pi AI camera optics path.
|
| double | viewportFov (int width, int height) const |
| | Choose the simulator viewport field of view.
|
Validated camera, route, simulator-startup, and output settings.
fov is vertical degrees; positions are WGS-84 and altitudes are metres. Startup weather/time readback and capture timing remain provenance, not a sensor exposure clock.
Definition at line 60 of file route.h.
◆ cameraAgl()
| double pangea_survey::Config::cameraAgl |
( |
double | nominalAgl | ) |
const |
|
inline |
Resolve the camera's height above ground.
- Parameters
-
| nominalAgl | Route height in metres. |
- Returns
- Configured map-camera height, or
nominalAgl if unset.
Definition at line 110 of file route.h.
◆ cameraFov()
| double pangea_survey::Config::cameraFov |
( |
| ) |
const |
|
inline |
Compute field of view at the selected map-camera height.
- Returns
- Field of view in degrees.
Preserve the starting ground footprint by scaling the tangent of the half-angle, not the angle itself.
Definition at line 103 of file route.h.
◆ piCamera()
| bool pangea_survey::Config::piCamera |
( |
| ) |
const |
|
inline |
Check for the calibrated Raspberry Pi AI camera optics path.
- Returns
- True when the route selects that profile.
Definition at line 115 of file route.h.
◆ timedPhotoDue()
| bool pangea_survey::Config::timedPhotoDue |
( |
double | elapsed, |
|
|
double | nextPhoto ) const |
|
inline |
Check whether an enabled timed capture has reached its deadline.
- Parameters
-
| elapsed | Seconds elapsed in the session. |
| nextPhoto | Scheduled time in the same elapsed-time domain. |
- Returns
- True when timed capture is enabled and due.
Definition at line 96 of file route.h.
◆ viewportFov()
| double pangea_survey::Config::viewportFov |
( |
int | width, |
|
|
int | height ) const |
|
inline |
Choose the simulator viewport field of view.
- Parameters
-
| width | Viewport columns in pixels. |
| height | Viewport rows in pixels. |
- Returns
- Field of view in degrees.
The Pi optics path accounts for viewport shape and capture inset; the generic path uses the height-adjusted configuration.
Definition at line 122 of file route.h.
◆ autoEnterFlight
| bool pangea_survey::Config::autoEnterFlight = true |
◆ captureInset
| int pangea_survey::Config::captureInset = 0 |
◆ captureMargin
| bool pangea_survey::Config::captureMargin = false |
◆ end
| Point pangea_survey::Config::end |
◆ exifSettings
◆ fov
| double pangea_survey::Config::fov = 60 |
◆ grab
| int pangea_survey::Config::grab = 2 |
◆ iniDirectory
| std::filesystem::path pangea_survey::Config::iniDirectory |
◆ interval
| double pangea_survey::Config::interval = 4 |
◆ ivyAddress
| std::string pangea_survey::Config::ivyAddress = "127.255.255.255:2010" |
◆ ivyAircraftId
| int pangea_survey::Config::ivyAircraftId = -1 |
◆ ivyEnabled
| bool pangea_survey::Config::ivyEnabled = false |
◆ jpegHeight
| int pangea_survey::Config::jpegHeight = 1520 |
◆ jpegWidth
| int pangea_survey::Config::jpegWidth = 2028 |
◆ lens
◆ lensProfile
| std::string pangea_survey::Config::lensProfile = "simconnect" |
◆ lockStartAltitude
| bool pangea_survey::Config::lockStartAltitude = true |
◆ mapCameraAgl
| double pangea_survey::Config::mapCameraAgl = 0 |
◆ output
| std::filesystem::path pangea_survey::Config::output |
◆ quality
| unsigned long pangea_survey::Config::quality = 92 |
◆ settle
| double pangea_survey::Config::settle = 10 |
◆ speed
| double pangea_survey::Config::speed = 20 |
◆ start
| Point pangea_survey::Config::start |
◆ startupAirport
| std::string pangea_survey::Config::startupAirport = "EHRD" |
◆ startupFlight
| std::string pangea_survey::Config::startupFlight = "auto" |
◆ startupMaximizeMinimized
| bool pangea_survey::Config::startupMaximizeMinimized = true |
◆ startupTimeout
| double pangea_survey::Config::startupTimeout = 0 |
◆ startupUtc
| std::optional<UtcDateTime> pangea_survey::Config::startupUtc |
◆ tileOverlap
| double pangea_survey::Config::tileOverlap = 0.15 |
◆ tileSettle
| double pangea_survey::Config::tileSettle = 0.05 |
◆ weatherPreset
| std::string pangea_survey::Config::weatherPreset = "unchanged" |
◆ weatherReadback
| std::filesystem::path pangea_survey::Config::weatherReadback |
The documentation for this struct was generated from the following file: