
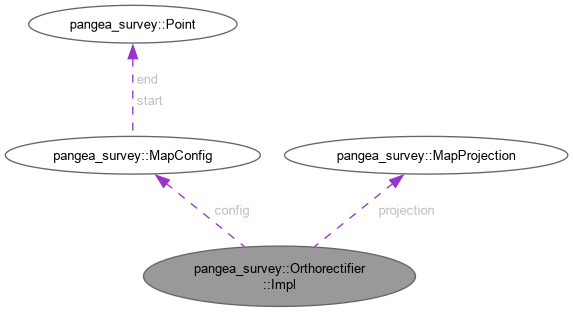
Data Structures | |
| struct | CachedBlock |
| struct | SourcePhoto |
| struct | MosaicView |
| struct | CachedPhoto |
Public Member Functions | |
| std::shared_ptr< Photo > | sourcePhoto (std::size_t index) |
| Get a pinned decoded photo for the simple renderer. | |
| Photo & | mosaicPhoto (std::size_t index) |
| Get the mosaic's cached projection and image source. | |
| void | prepareDiskSources (const std::function< bool()> &stopped) |
| Prepare disk-backed rasters for low-memory rendering. | |
| cv::Rect | mosaicRectangle (const OrthoSource &source, int scale, bool seamPlan=false) const |
| Bound the projected source footprint on a mosaic grid. | |
| cv::Matx33d | mosaicWarp (const Photo &photo, const cv::Rect &rectangle, int scale, cv::Mat &image, cv::Mat &mask) const |
| Resample one source over a mosaic rectangle. | |
| void | prepareMosaic (const std::function< bool()> &stopped) |
| Build the shared seam and exposure plan on first use. | |
| void | prepareMosaicCompletion (const std::vector< cv::UMat > &images, const std::vector< cv::UMat > &originalMasks, const std::vector< std::size_t > &seamViews, const std::function< bool()> &stopped) |
| Build a shared fill overview while retaining observed support. | |
| OrthoImage | renderMosaicRegion (const MapTile &map, int width, int height, const std::function< bool()> &stopped) |
| Render a mosaic window using the session-wide seam plan. | |
| OrthoImage | renderRegion (const MapTile &map, int width, int height, const std::function< bool()> &stopped) |
| Render a window with the selected orthorectification engine. | |
| Impl (const MapConfig &c, const std::filesystem::path &csv) | |
| Admit a source set and establish the shared projection and grid. | |
Data Fields | |
| MapConfig | config |
| MapProjection | projection |
| std::vector< OrthoSource > | sources |
| double | west = 0 |
| double | north = 0 |
| std::size_t | cols = 0 |
| std::size_t | rows = 0 |
| std::map< std::pair< std::size_t, std::size_t >, CachedBlock > | blocks |
| std::size_t | blockClock = 0 |
| std::map< std::size_t, SourcePhoto > | sourcePhotos |
| std::size_t | sourcePhotoBytes = 0 |
| std::size_t | sourcePhotoClock = 0 |
| std::vector< MosaicView > | mosaicViews |
| std::map< std::size_t, CachedPhoto > | mosaicPhotos |
| std::size_t | photoClock = 0 |
| std::size_t | photoBytes = 0 |
| int | seamScale = 0 |
| cv::Mat | completedMosaic |
| cv::Mat | mosaicSourceDistance |
| std::vector< std::filesystem::path > | sourceRasters |
| bool | mosaicPrepared = false |
| bool | diskSourcesPrepared = false |
Detailed Description
Definition at line 402 of file ortho_map.cpp.
Constructor & Destructor Documentation
◆ Impl()
|
inline |
Admit a source set and establish the shared projection and grid.
- Parameters
-
c Requested configuration. csv Source manifest used by the selected input path.
Reconcile the manifest count and choose a reference plane before rendering; camera heights must leave clearance above that plane.
- Exceptions
-
std::runtime_error On invalid input, engine, or layout.
Definition at line 445 of file ortho_map.cpp.
Member Function Documentation
◆ mosaicPhoto()
| Photo & pangea_survey::Orthorectifier::Impl::mosaicPhoto | ( | std::size_t | index | ) |
Get the mosaic's cached projection and image source.
- Parameters
-
index Index in the admitted source list.
- Returns
- Borrowed entry that can be invalidated by cache eviction.
Low-memory mode retains a raster path instead of decoded pixels; otherwise evict by recency before allocating the next image.
Definition at line 649 of file ortho_map.cpp.
◆ mosaicRectangle()
| cv::Rect pangea_survey::Orthorectifier::Impl::mosaicRectangle | ( | const OrthoSource & | source, |
| int | scale, | ||
| bool | seamPlan = false ) const |
Bound the projected source footprint on a mosaic grid.
- Parameters
-
source Source pose and camera geometry. scale Number of base pixels per grid pixel. seamPlan True when computing the seam-planning footprint.
- Returns
- Pixel rectangle in the selected mosaic grid.
Project image corners to the common reference plane so the renderer can avoid processing unrelated regions.
Definition at line 683 of file ortho_map.cpp.
◆ mosaicWarp()
| cv::Matx33d pangea_survey::Orthorectifier::Impl::mosaicWarp | ( | const Photo & | photo, |
| const cv::Rect & | rectangle, | ||
| int | scale, | ||
| cv::Mat & | image, | ||
| cv::Mat & | mask ) const |
Resample one source over a mosaic rectangle.
- Parameters
-
photo Projection-ready source with decoded or disk-backed pixels. rectangle Output window in mosaic-grid pixels. scale Number of base pixels per grid pixel. [out] image Warped source colour. [out] mask Support for the warped colour.
- Returns
- Transform mapping local destination coordinates into the source.
Evaluate the mapping at pixel centres; use the calibrated camera when present and process in strips to bound source access.
Definition at line 732 of file ortho_map.cpp.
◆ prepareDiskSources()
| void pangea_survey::Orthorectifier::Impl::prepareDiskSources | ( | const std::function< bool()> & | stopped | ) |
Prepare disk-backed rasters for low-memory rendering.
- Parameters
-
stopped Cooperative cancellation predicate.
Identify each raster with its input digest so reusable prepared data cannot quietly stand in for changed source imagery.
- Exceptions
-
std::runtime_error On cancellation or invalid source data or storage.
Definition at line 525 of file ortho_map.cpp.
◆ prepareMosaic()
| void pangea_survey::Orthorectifier::Impl::prepareMosaic | ( | const std::function< bool()> & | stopped | ) |
Build the shared seam and exposure plan on first use.
- Parameters
-
stopped Cooperative cancellation predicate.
Coarsen the overview until the global planning workspace fits its limits. Reuse that plan across windows so adjacent renders agree.
Definition at line 828 of file ortho_map.cpp.
◆ prepareMosaicCompletion()
| void pangea_survey::Orthorectifier::Impl::prepareMosaicCompletion | ( | const std::vector< cv::UMat > & | images, |
| const std::vector< cv::UMat > & | originalMasks, | ||
| const std::vector< std::size_t > & | seamViews, | ||
| const std::function< bool()> & | stopped ) |
Build a shared fill overview while retaining observed support.
- Parameters
-
images Warped colour overviews. originalMasks Matching support masks before seam selection. seamViews Source indices corresponding to the overview entries. stopped Cooperative cancellation predicate.
Keep the observed mask separate from inferred fill so later renders need not report extrapolated colours as measured coverage.
Definition at line 944 of file ortho_map.cpp.
◆ renderMosaicRegion()
| OrthoImage pangea_survey::Orthorectifier::Impl::renderMosaicRegion | ( | const MapTile & | map, |
| int | width, | ||
| int | height, | ||
| const std::function< bool()> & | stopped ) |
Render a mosaic window using the session-wide seam plan.
- Parameters
-
map Projected centre and georeference of the window. width Output columns. height Output rows. stopped Cooperative cancellation predicate.
- Returns
- Owned pixels, confidence, and rendering provenance.
Combine planned contributions in the local window while tracking fallback colour and coverage independently of multiband blending.
Definition at line 1003 of file ortho_map.cpp.
◆ renderRegion()
| OrthoImage pangea_survey::Orthorectifier::Impl::renderRegion | ( | const MapTile & | map, |
| int | outputWidth, | ||
| int | outputHeight, | ||
| const std::function< bool()> & | stopped ) |
Render a window with the selected orthorectification engine.
- Parameters
-
map Projected centre and georeference of the window. outputWidth Output columns. outputHeight Output rows. stopped Cooperative cancellation predicate.
- Returns
- Owned pixels and coverage information.
The simple engine ranks sources by distance and bounds the candidate set; the mosaic engine uses the shared seam plan instead.
Definition at line 1222 of file ortho_map.cpp.
◆ sourcePhoto()
| std::shared_ptr< Photo > pangea_survey::Orthorectifier::Impl::sourcePhoto | ( | std::size_t | index | ) |
Get a pinned decoded photo for the simple renderer.
- Parameters
-
index Index in the admitted source list.
- Returns
- Shared ownership of the decoded, projection-ready photo.
Evict least-recently-used entries only when the cache is their sole owner; active renders must retain their pixel storage.
- Exceptions
-
std::runtime_error If the decoded-photo budget cannot be met.
Definition at line 486 of file ortho_map.cpp.
Field Documentation
◆ blockClock
| std::size_t pangea_survey::Orthorectifier::Impl::blockClock = 0 |
Definition at line 410 of file ortho_map.cpp.
◆ blocks
| std::map<std::pair<std::size_t, std::size_t>, CachedBlock> pangea_survey::Orthorectifier::Impl::blocks |
Definition at line 409 of file ortho_map.cpp.
◆ cols
| std::size_t pangea_survey::Orthorectifier::Impl::cols = 0 |
Definition at line 407 of file ortho_map.cpp.
◆ completedMosaic
| cv::Mat pangea_survey::Orthorectifier::Impl::completedMosaic |
Definition at line 427 of file ortho_map.cpp.
◆ config
| MapConfig pangea_survey::Orthorectifier::Impl::config |
Definition at line 403 of file ortho_map.cpp.
◆ diskSourcesPrepared
| bool pangea_survey::Orthorectifier::Impl::diskSourcesPrepared = false |
Definition at line 429 of file ortho_map.cpp.
◆ mosaicPhotos
| std::map<std::size_t, CachedPhoto> pangea_survey::Orthorectifier::Impl::mosaicPhotos |
Definition at line 424 of file ortho_map.cpp.
◆ mosaicPrepared
| bool pangea_survey::Orthorectifier::Impl::mosaicPrepared = false |
Definition at line 429 of file ortho_map.cpp.
◆ mosaicSourceDistance
| cv::Mat pangea_survey::Orthorectifier::Impl::mosaicSourceDistance |
Definition at line 427 of file ortho_map.cpp.
◆ mosaicViews
| std::vector<MosaicView> pangea_survey::Orthorectifier::Impl::mosaicViews |
Definition at line 423 of file ortho_map.cpp.
◆ north
| double pangea_survey::Orthorectifier::Impl::north = 0 |
Definition at line 406 of file ortho_map.cpp.
◆ photoBytes
| std::size_t pangea_survey::Orthorectifier::Impl::photoBytes = 0 |
Definition at line 425 of file ortho_map.cpp.
◆ photoClock
| std::size_t pangea_survey::Orthorectifier::Impl::photoClock = 0 |
Definition at line 425 of file ortho_map.cpp.
◆ projection
| MapProjection pangea_survey::Orthorectifier::Impl::projection |
Definition at line 404 of file ortho_map.cpp.
◆ rows
| std::size_t pangea_survey::Orthorectifier::Impl::rows = 0 |
Definition at line 407 of file ortho_map.cpp.
◆ seamScale
| int pangea_survey::Orthorectifier::Impl::seamScale = 0 |
Definition at line 426 of file ortho_map.cpp.
◆ sourcePhotoBytes
| std::size_t pangea_survey::Orthorectifier::Impl::sourcePhotoBytes = 0 |
Definition at line 413 of file ortho_map.cpp.
◆ sourcePhotoClock
| std::size_t pangea_survey::Orthorectifier::Impl::sourcePhotoClock = 0 |
Definition at line 413 of file ortho_map.cpp.
◆ sourcePhotos
| std::map<std::size_t, SourcePhoto> pangea_survey::Orthorectifier::Impl::sourcePhotos |
Definition at line 412 of file ortho_map.cpp.
◆ sourceRasters
| std::vector<std::filesystem::path> pangea_survey::Orthorectifier::Impl::sourceRasters |
Definition at line 428 of file ortho_map.cpp.
◆ sources
| std::vector<OrthoSource> pangea_survey::Orthorectifier::Impl::sources |
Definition at line 405 of file ortho_map.cpp.
◆ west
| double pangea_survey::Orthorectifier::Impl::west = 0 |
Definition at line 406 of file ortho_map.cpp.
The documentation for this struct was generated from the following file:
- modules/pangea/ortho_map.cpp