
Loading...
Searching...
No Matches
usher_capture_arbiter_shoot_union Union Reference
FC-to-USHER spatial observation request, not a physical shutter acknowledgement. More...
#include <usher_protocol.h>
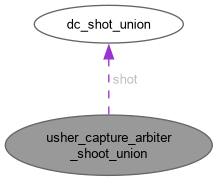
Collaboration diagram for usher_capture_arbiter_shoot_union:
Data Fields | |
| struct { | |
| union dc_shot_union shot | |
| uint32_t session | |
| uint32_t camera_mask | |
| uint32_t fc_time_us | |
| } | data |
| uint8_t | bin [USHER_CAPTURE_ARBITER_SHOOT_MSG_SIZE] |
Detailed Description
FC-to-USHER spatial observation request, not a physical shutter acknowledgement.
shot retains the original FC number/pose, camera_mask may select several sensors, and fc_time_us is in the FC's wrapping clock domain. Never compare that timestamp directly with MORA monotonic time. Each camera completes independently.
Definition at line 358 of file usher_protocol.h.
Field Documentation
◆ bin
| uint8_t usher_capture_arbiter_shoot_union::bin[USHER_CAPTURE_ARBITER_SHOOT_MSG_SIZE] |
Definition at line 360 of file usher_protocol.h.
◆ camera_mask
| uint32_t usher_capture_arbiter_shoot_union::camera_mask |
Definition at line 359 of file usher_protocol.h.
◆ [struct]
| struct { ... } usher_capture_arbiter_shoot_union::data |
◆ fc_time_us
| uint32_t usher_capture_arbiter_shoot_union::fc_time_us |
Definition at line 359 of file usher_protocol.h.
◆ session
| uint32_t usher_capture_arbiter_shoot_union::session |
Definition at line 359 of file usher_protocol.h.
◆ shot
| union dc_shot_union usher_capture_arbiter_shoot_union::shot |
Definition at line 359 of file usher_protocol.h.
The documentation for this union was generated from the following file:
- src/usher_protocol.h