
Optional non-image camera adapter for the native Diplacam worker. More...
#include "camera_backend.h"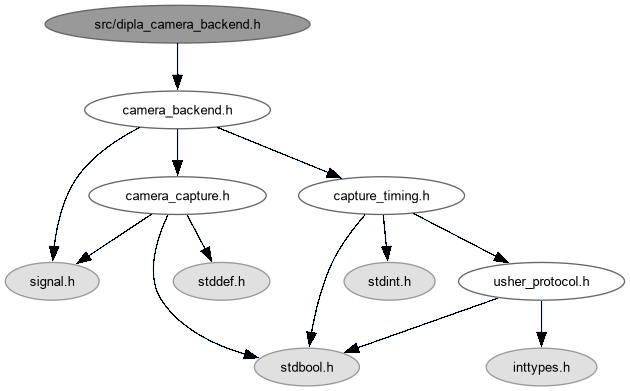
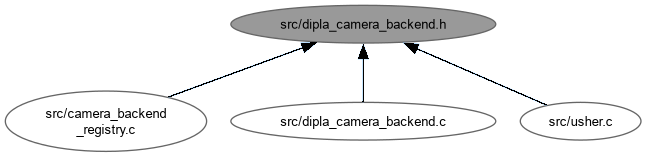
Go to the source code of this file.
Functions | |
| bool | dipla_camera_backend_setup (const char *configuration) |
| Select the worker experiment before acquiring its process. | |
| struct camera_backend | dipla_camera_backend_get (void) |
| Describe camera slot five without starting work. | |
Detailed Description
Optional non-image camera adapter for the native Diplacam worker.
This boundary owns a local worker process and reply correlation. It does not run inference, move FC waypoints or select mission blocks.
Definition in file dipla_camera_backend.h.
Function Documentation
◆ dipla_camera_backend_get()
| struct camera_backend dipla_camera_backend_get | ( | void | ) |
Describe camera slot five without starting work.
- Returns
- Native non-image backend with process-owned point-stream callbacks.
Static callback lifetimes let USHER retain the descriptor safely; camera admission remains separate from route readiness.
Definition at line 285 of file dipla_camera_backend.c.
◆ dipla_camera_backend_setup()
| bool dipla_camera_backend_setup | ( | const char * | configuration | ) |
Select the worker experiment before acquiring its process.
- Parameters
-
configuration Nonempty worker-INI path, copied into bounded storage.
- Returns
- False for an invalid/overlong path or an already acquired channel.
Copying prevents an argv buffer from becoming a dangling configuration pointer. Setup does not open the field, initialize ONNX or acquire a sensor.
Definition at line 66 of file dipla_camera_backend.c.