
Function table describing one backend's owned camera operations. More...
#include <camera_backend.h>
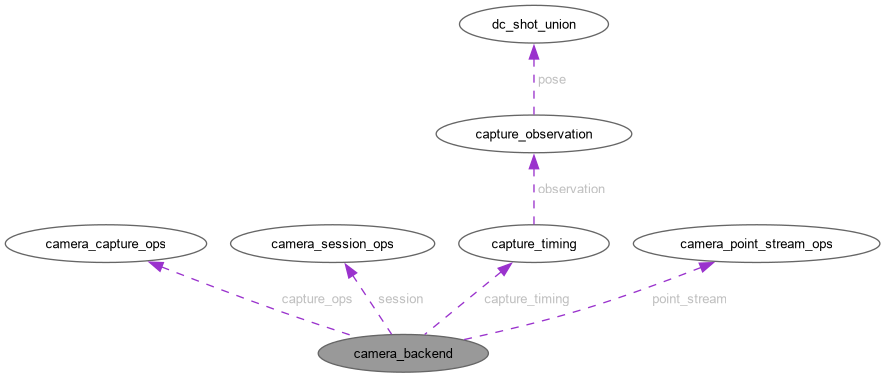
Data Fields | |
| const char * | name |
| Stable backend name used for logs and diagnostics. | |
| int(* | init )(const char *source_image) |
| Initialize backend resources; optional mock image path is borrowed. | |
| int(* | shoot )(char *filename, size_t filename_size, int image_number) |
| Trigger one photo and return the backend's owned staging path. | |
| void(* | deinit )(void) |
| Release backend resources and reap owned children. | |
| const char * | soda_application |
| Optional SODA application name for this backend's saved files. | |
| const struct camera_capture_ops * | capture_ops |
| Optional split-phase capture lifecycle. | |
| uint8_t | camera_id |
| char | prefix |
| struct { | |
| size_t width | |
| size_t height | |
| const char * filename_marker | |
| } | mock |
| unsigned | capabilities |
| const char * | soda_option |
| int(* | init_cancelable )(const char *source_image, const volatile sig_atomic_t *running) |
| int(* | record )(const union dc_shot_union *shot) |
| const struct camera_session_ops * | session |
| void(* | configure )(const struct camera_backend_host *host) |
| void(* | pose_updated )(void) |
| double(* | capture_delay )(void) |
| struct capture_timing(* | capture_timing )(void) |
| int(* | geolocate )(char *filename) |
| bool(* | bind_frame )(uint64_t sequence, uint64_t sensor_timestamp_ns) |
| void(* | detection_summary )(char *buffer, size_t size) |
| void(* | save_detection_copy )(const char *filename) |
| const char * | photo_directory |
| void(* | image_saved )(const char *filename, const union dc_shot_union *shot) |
| const struct camera_point_stream_ops * | point_stream |
| Optional repeated point stream, independent of start/stop sessions. | |
| uint32_t | control_capabilities |
| Bitset of controls supported by this backend; zero means none. | |
| int(* | control_init )(void) |
| Initialize control-only ownership without forcing photo capture setup. | |
| uint8_t(* | control )(uint8_t command, uint8_t value, uint8_t *observed, uint8_t *evidence) |
| Execute one validated control and return command-specific evidence. | |
Detailed Description
Function table describing one backend's owned camera operations.
Required capture hooks are selected by the advertised capability bits. Optional sessions, point streams, controls, and analysis hooks remain backend-owned; USHER does not infer support from a camera ID or name.
Definition at line 94 of file camera_backend.h.
Field Documentation
◆ bind_frame
| bool(* camera_backend::bind_frame) (uint64_t sequence, uint64_t sensor_timestamp_ns) |
Definition at line 124 of file camera_backend.h.
◆ camera_id
| uint8_t camera_backend::camera_id |
Definition at line 107 of file camera_backend.h.
◆ capabilities
| unsigned camera_backend::capabilities |
Definition at line 114 of file camera_backend.h.
◆ capture_delay
| double(* camera_backend::capture_delay) (void) |
Definition at line 121 of file camera_backend.h.
◆ capture_ops
| const struct camera_capture_ops* camera_backend::capture_ops |
Optional split-phase capture lifecycle.
Definition at line 106 of file camera_backend.h.
◆ capture_timing
| struct capture_timing(* camera_backend::capture_timing) (void) |
Definition at line 121 of file camera_backend.h.
◆ configure
| void(* camera_backend::configure) (const struct camera_backend_host *host) |
Definition at line 119 of file camera_backend.h.
◆ control
| uint8_t(* camera_backend::control) (uint8_t command, uint8_t value, uint8_t *observed, uint8_t *evidence) |
Execute one validated control and return command-specific evidence.
Definition at line 137 of file camera_backend.h.
◆ control_capabilities
| uint32_t camera_backend::control_capabilities |
Bitset of controls supported by this backend; zero means none.
Definition at line 133 of file camera_backend.h.
◆ control_init
| int(* camera_backend::control_init) (void) |
Initialize control-only ownership without forcing photo capture setup.
Definition at line 135 of file camera_backend.h.
◆ deinit
| void(* camera_backend::deinit) (void) |
Release backend resources and reap owned children.
Definition at line 102 of file camera_backend.h.
◆ detection_summary
| void(* camera_backend::detection_summary) (char *buffer, size_t size) |
Definition at line 125 of file camera_backend.h.
◆ filename_marker
| const char* camera_backend::filename_marker |
Definition at line 112 of file camera_backend.h.
◆ geolocate
| int(* camera_backend::geolocate) (char *filename) |
Definition at line 123 of file camera_backend.h.
◆ height
| size_t camera_backend::height |
Definition at line 111 of file camera_backend.h.
◆ image_saved
| void(* camera_backend::image_saved) (const char *filename, const union dc_shot_union *shot) |
Optional post-publication hook; may enqueue work but must not wait for inference.
Definition at line 129 of file camera_backend.h.
◆ init
| int(* camera_backend::init) (const char *source_image) |
Initialize backend resources; optional mock image path is borrowed.
Definition at line 98 of file camera_backend.h.
◆ init_cancelable
| int(* camera_backend::init_cancelable) (const char *source_image, const volatile sig_atomic_t *running) |
Definition at line 116 of file camera_backend.h.
◆ [struct]
| struct { ... } camera_backend::mock |
Backend-owned geometry and namespace for shared simulation capture.
◆ name
| const char* camera_backend::name |
Stable backend name used for logs and diagnostics.
Definition at line 96 of file camera_backend.h.
◆ photo_directory
| const char* camera_backend::photo_directory |
Definition at line 127 of file camera_backend.h.
◆ point_stream
| const struct camera_point_stream_ops* camera_backend::point_stream |
Optional repeated point stream, independent of start/stop sessions.
Definition at line 131 of file camera_backend.h.
◆ pose_updated
| void(* camera_backend::pose_updated) (void) |
Definition at line 120 of file camera_backend.h.
◆ prefix
| char camera_backend::prefix |
Definition at line 108 of file camera_backend.h.
◆ record
| int(* camera_backend::record) (const union dc_shot_union *shot) |
Definition at line 117 of file camera_backend.h.
◆ save_detection_copy
| void(* camera_backend::save_detection_copy) (const char *filename) |
Definition at line 126 of file camera_backend.h.
◆ session
| const struct camera_session_ops* camera_backend::session |
Definition at line 118 of file camera_backend.h.
◆ shoot
| int(* camera_backend::shoot) (char *filename, size_t filename_size, int image_number) |
Trigger one photo and return the backend's owned staging path.
Definition at line 100 of file camera_backend.h.
◆ soda_application
| const char* camera_backend::soda_application |
Optional SODA application name for this backend's saved files.
Definition at line 104 of file camera_backend.h.
◆ soda_option
| const char* camera_backend::soda_option |
Definition at line 115 of file camera_backend.h.
◆ width
| size_t camera_backend::width |
Definition at line 111 of file camera_backend.h.
The documentation for this struct was generated from the following file:
- src/camera_backend.h