
USHER-side supervisor for the persistent LWIR capture-server process. More...
#include "lwir_cam_pipe.h"#include "camera_capture.h"#include "../modules/lwir_cam/lwir_features.h"#include "path_utils.h"#include <errno.h>#include <fcntl.h>#include <limits.h>#include <math.h>#include <poll.h>#include <signal.h>#include <spawn.h>#include <stdio.h>#include <stdlib.h>#include <string.h>#include <sys/stat.h>#include <sys/types.h>#include <sys/wait.h>#include <time.h>#include <unistd.h>#include "camera_backend.h"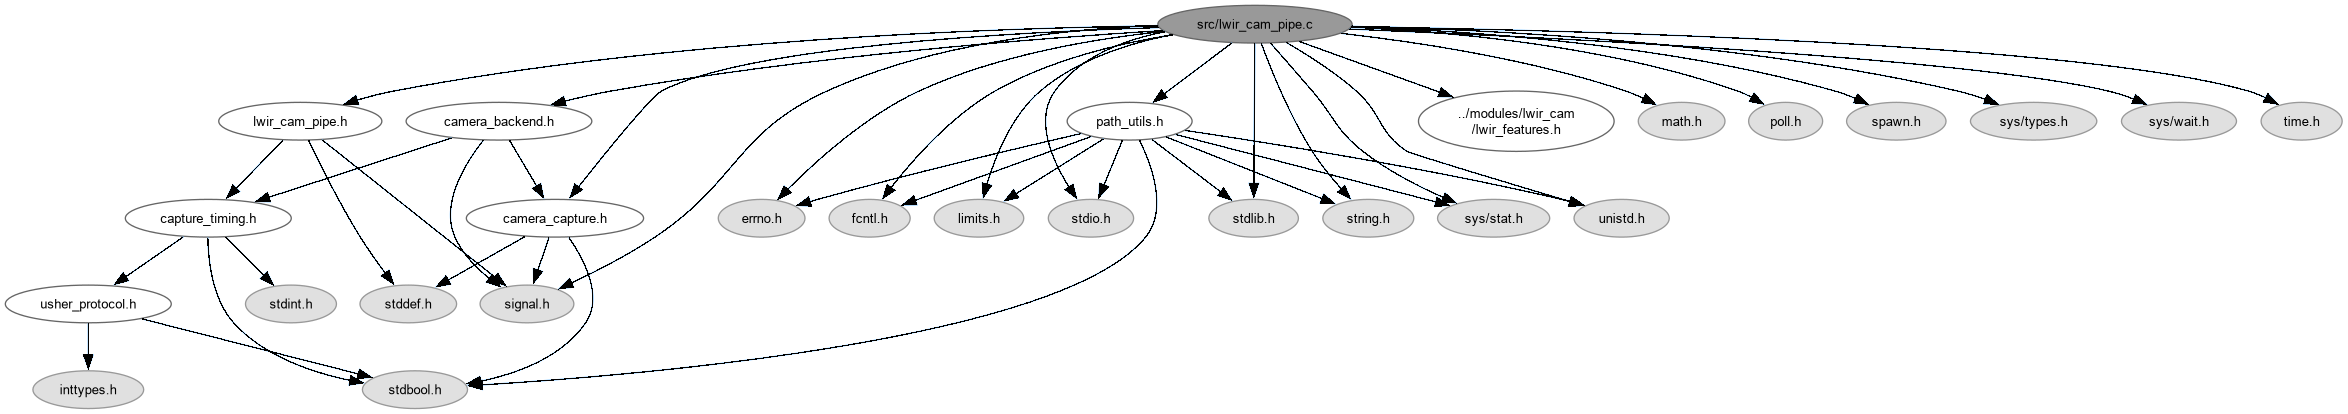
Go to the source code of this file.
Macros | |
| #define | USHER_LWIR_CAM_PHOTO_DIR "~/Pictures/sensoraia" |
| #define | USHER_LWIR_CAM_COMMAND "./bin/lwircam" |
| #define | CHILD_STOP_GRACE_MS 500 |
| #define | CHILD_WAIT_INTERVAL_MS 10 |
| #define | IMAGE_PROCESS_TIMEOUT_MS 30000 |
| #define | LWIR_SERVER_START_TIMEOUT_MS 30000 |
| #define | LWIR_WARMUP_TIMEOUT_MS 30000 |
| #define | LWIR_REQUEST_TIMEOUT_MS 8000 |
Functions | |
| void | lwir_cam_pipe_configure (const struct camera_backend_host *host) |
| Bind the owner's long-lived shutdown flag before starting workers. | |
| int | lwir_cam_pipe_set_config (const char *path) |
| Apply a bounded worker configuration before starting the capture server. | |
| static uint64_t | monotonic_ms (void) |
| Read the capture-server watchdog clock. | |
| static int | wait_child (pid_t pid, int *status, int timeout_ms) |
| Wait up to a bounded time for the capture child to exit. | |
| static int | terminate_child (pid_t pid, int *status) |
| Stop an owned capture child, escalating only after its grace period. | |
| static int | create_cloexec_pipe (int descriptors[2]) |
| Open a close-on-exec pipe for child protocol setup. | |
| void | lwir_cam_pipe_set_photo_directory (const char *directory) |
| Override the output directory for an isolated standalone benchmark. | |
| void | lwir_cam_pipe_set_native_raw (int enabled) |
| Select whether successful captures keep an explicit .raw companion. | |
| int | lwir_cam_pipe_set_calibration (const char *path) |
| Set the optional calibration file used by server-side geolocation. | |
| struct capture_timing | lwir_cam_pipe_capture_timing (void) |
| Return detailed callback or polling timing evidence for the last capture. | |
| static int | parse_capture_timing (const char *text, struct capture_timing *timing, bool callback) |
| Parse one server timing payload after its protocol prefix. | |
| double | lwir_cam_pipe_capture_delay (void) |
| Return the delay of the last successful capture request in seconds. | |
| static int | read_server_status (const char *expected, int timeout_ms, const volatile sig_atomic_t *keep_running) |
| Read server diagnostic lines until an expected terminal reply arrives. | |
| static void | stop_capture_server (void) |
| Close pipes and reap or terminate the owned capture server. | |
| static int | send_request_and_wait (const char *request, size_t request_size, int timeout_ms, const char *expected) |
| Send one newline-terminated server request and require an OK reply. | |
| static int | start_capture_server (const char *unused, const volatile sig_atomic_t *keep_running) |
| Start the persistent thermal capture subprocess. | |
| int | lwir_cam_pipe_init (const char *unused) |
| Start and qualify the persistent LWIR capture server. | |
| int | lwir_cam_pipe_init_cancelable (const char *unused, const volatile sig_atomic_t *keep_running) |
| Start the server but abort promptly when USHER begins shutdown. | |
| int | lwir_cam_pipe_warmup (void) |
| Open, stabilize, and close the sensor without writing an image. | |
| int | lwir_cam_pipe_process_mock (char *filename) |
| Process a mock thermal image for hardware-free local testing. | |
| int | lwir_cam_pipe_geolocate (char *filename) |
| Add thermal hotspot/geolocation metadata through the running server. | |
| int | lwir_cam_pipe_shoot (char *filename, size_t filename_size, int image_number) |
| Request one thermal JPEG from an initialized capture server. | |
| void | lwir_cam_pipe_deinit (void) |
| Stop, reap, and forget the persistent LWIR capture server. | |
Variables | |
| char ** | environ |
| static pid_t | capture_server_pid = -1 |
| static int | capture_server_input = -1 |
| static int | capture_server_output = -1 |
| static char | status_buffer [512] |
| static size_t | status_buffer_size |
| static size_t | status_buffer_pos |
| static double | capture_delay_s = -1 |
| static struct capture_timing | capture_times |
| static bool | native_raw_enabled |
| static const char * | calibration_path |
| static const char * | photo_directory = USHER_LWIR_CAM_PHOTO_DIR |
| static const char * | capture_command = USHER_LWIR_CAM_COMMAND |
| static const char * | lwir_config |
| static const volatile sig_atomic_t * | running |
Detailed Description
USHER-side supervisor for the persistent LWIR capture-server process.
The server holds the Tiny1-C stream open, avoiding per-shot sensor warmup. This parent owns its pipes and child lifecycle, validates line-protocol replies and capture timing. All failure paths clear state before returning so USHER's supervisor can schedule a later retry without reusing a stale descriptor.
Definition in file lwir_cam_pipe.c.
Macro Definition Documentation
◆ CHILD_STOP_GRACE_MS
| #define CHILD_STOP_GRACE_MS 500 |
Definition at line 59 of file lwir_cam_pipe.c.
◆ CHILD_WAIT_INTERVAL_MS
| #define CHILD_WAIT_INTERVAL_MS 10 |
Definition at line 61 of file lwir_cam_pipe.c.
◆ IMAGE_PROCESS_TIMEOUT_MS
| #define IMAGE_PROCESS_TIMEOUT_MS 30000 |
Definition at line 62 of file lwir_cam_pipe.c.
◆ LWIR_REQUEST_TIMEOUT_MS
| #define LWIR_REQUEST_TIMEOUT_MS 8000 |
Definition at line 68 of file lwir_cam_pipe.c.
◆ LWIR_SERVER_START_TIMEOUT_MS
| #define LWIR_SERVER_START_TIMEOUT_MS 30000 |
Definition at line 64 of file lwir_cam_pipe.c.
◆ LWIR_WARMUP_TIMEOUT_MS
| #define LWIR_WARMUP_TIMEOUT_MS 30000 |
Definition at line 66 of file lwir_cam_pipe.c.
◆ USHER_LWIR_CAM_COMMAND
| #define USHER_LWIR_CAM_COMMAND "./bin/lwircam" |
Definition at line 55 of file lwir_cam_pipe.c.
◆ USHER_LWIR_CAM_PHOTO_DIR
| #define USHER_LWIR_CAM_PHOTO_DIR "~/Pictures/sensoraia" |
Definition at line 51 of file lwir_cam_pipe.c.
Function Documentation
◆ create_cloexec_pipe()
|
static |
Open a close-on-exec pipe for child protocol setup.
- Parameters
-
[out] descriptors Read and write descriptors; valid only on success.
- Returns
- Zero on success, or -1 with errno on failure.
Keep both descriptors above stderr so child's descriptor redirection cannot alias an endpoint when a standard descriptor was closed.
Definition at line 156 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_capture_delay()
| double lwir_cam_pipe_capture_delay | ( | void | ) |
Return the delay of the last successful capture request in seconds.
- Returns
- Nonnegative delay, or a negative value when no timing is available.
Definition at line 242 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_capture_timing()
| struct capture_timing lwir_cam_pipe_capture_timing | ( | void | ) |
Return detailed callback or polling timing evidence for the last capture.
- Returns
- Timing structure; use capture_timing_valid() before consuming it.
Definition at line 202 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_configure()
| void lwir_cam_pipe_configure | ( | const struct camera_backend_host * | host | ) |
Bind the owner's long-lived shutdown flag before starting workers.
- Parameters
-
host Only its running flag is retained; NULL clears the binding.
Definition at line 90 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_deinit()
| void lwir_cam_pipe_deinit | ( | void | ) |
Stop, reap, and forget the persistent LWIR capture server.
Definition at line 707 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_geolocate()
| int lwir_cam_pipe_geolocate | ( | char * | filename | ) |
Add thermal hotspot/geolocation metadata through the running server.
- Parameters
-
[in] filename JPEG to update.
- Returns
- 0 on success or -1 if the operation cannot be completed.
Definition at line 623 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_init()
| int lwir_cam_pipe_init | ( | const char * | unused | ) |
Start and qualify the persistent LWIR capture server.
- Parameters
-
unused Reserved common backend argument.
- Returns
- 0 after the server reports ready, otherwise -1.
Definition at line 520 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_init_cancelable()
| int lwir_cam_pipe_init_cancelable | ( | const char * | unused, |
| const volatile sig_atomic_t * | keep_running ) |
Start the server but abort promptly when USHER begins shutdown.
- Parameters
-
unused Reserved common backend argument. keep_running Signal-safe flag that remains nonzero while startup may continue.
- Returns
- 0 after the server reports ready, otherwise -1 after cleanup.
Definition at line 525 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_process_mock()
| int lwir_cam_pipe_process_mock | ( | char * | filename | ) |
Process a mock thermal image for hardware-free local testing.
- Parameters
-
[in,out] filename Input/output image path.
- Returns
- 0 on success or -1 on processing failure.
Definition at line 612 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_set_calibration()
| int lwir_cam_pipe_set_calibration | ( | const char * | path | ) |
Set the optional calibration file used by server-side geolocation.
- Parameters
-
path Nonempty calibration YAML path.
- Returns
- 0 on acceptance or -1 for an invalid path.
Definition at line 194 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_set_config()
| int lwir_cam_pipe_set_config | ( | const char * | path | ) |
Apply a bounded worker configuration before starting the capture server.
- Parameters
-
[in] path Configuration file path.
- Returns
- 0 when accepted, otherwise -1; live reconfiguration is not implied.
Definition at line 95 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_set_native_raw()
| void lwir_cam_pipe_set_native_raw | ( | int | enabled | ) |
Select whether successful captures keep an explicit .raw companion.
- Parameters
-
enabled Nonzero to request native raw output.
Definition at line 189 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_set_photo_directory()
| void lwir_cam_pipe_set_photo_directory | ( | const char * | directory | ) |
Override the output directory for an isolated standalone benchmark.
Definition at line 184 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_shoot()
| int lwir_cam_pipe_shoot | ( | char * | filename, |
| size_t | filename_size, | ||
| int | image_number ) |
Request one thermal JPEG from an initialized capture server.
- Parameters
-
filename Output path buffer, cleared on failure. filename_size Output path capacity. image_number USHER shot sequence.
- Returns
- 0 only for a verified nonempty output image, otherwise -1; USHER owns retry policy.
Definition at line 653 of file lwir_cam_pipe.c.
◆ lwir_cam_pipe_warmup()
| int lwir_cam_pipe_warmup | ( | void | ) |
Open, stabilize, and close the sensor without writing an image.
- Returns
- 0 after a stable warmup frame, otherwise -1.
Open the sensor once, wait past its power-on "wiggly" image, then close it again. Runs regardless of whether LWIR ends up selected for a shot, so a later real open (persistent server or standalone capture) never has to absorb that transient inline. Failure here is not fatal to USHER.
Definition at line 531 of file lwir_cam_pipe.c.
◆ monotonic_ms()
|
static |
Read the capture-server watchdog clock.
- Returns
- Monotonic milliseconds, or zero on failure.
Keep supervision independent of system time corrections.
Definition at line 105 of file lwir_cam_pipe.c.
◆ parse_capture_timing()
|
static |
Parse one server timing payload after its protocol prefix.
- Parameters
-
text Space-separated unsigned timing fields. timing Receives validated timing evidence. callback True for callback sequence/drop fields, false for polling timing.
- Returns
- 1 for valid evidence, 0 for malformed or implausible evidence.
Parsing is intentionally strict: timing metadata enriches EXIF but must never be accepted merely because a server process printed a vaguely similar line.
Definition at line 214 of file lwir_cam_pipe.c.
◆ read_server_status()
|
static |
Read server diagnostic lines until an expected terminal reply arrives.
- Parameters
-
expected Success line required to complete the operation. timeout_ms Whole-operation deadline. keep_running Optional cancellation flag; checked between bounded polls so stopping USHER need not wait for a thermal camera's full startup deadline.
- Returns
- 0 on the expected reply, -1 for cancellation, timeout, EOF, or server error.
Informational timing lines are parsed before the terminal reply. The buffer avoids a syscall per character while retaining line framing. One absolute deadline prevents a noisy or malicious child from extending an operation indefinitely.
Definition at line 256 of file lwir_cam_pipe.c.
◆ send_request_and_wait()
|
static |
Send one newline-terminated server request and require an OK reply.
Send one line request to the running server and wait for its reply. On any failure (broken pipe, dead process, or a timed-out/erroring reply) the server state is fully reset so a caller's retry starts with a clean respawn instead of repeatedly hitting the same stale, already-dead connection.
- Returns
- 0 on end-to-end success or -1 after fully resetting failed server state.
Definition at line 363 of file lwir_cam_pipe.c.
◆ start_capture_server()
|
static |
Start the persistent thermal capture subprocess.
- Parameters
-
unused Reserved backend argument. keep_running Optional shutdown flag used during the readiness wait.
- Returns
- Zero after readiness, or -1 on ownership, setup, or protocol failure.
Resolve any old owner before launching. Connect separate command and response pipes and require the startup acknowledgement before capture.
Definition at line 406 of file lwir_cam_pipe.c.
◆ stop_capture_server()
|
static |
Close pipes and reap or terminate the owned capture server.
Buffered response state is reset before the next spawn. Closing stdin asks cooperative server versions to exit; SIGTERM is used only when it remains alive.
Definition at line 333 of file lwir_cam_pipe.c.
◆ terminate_child()
|
static |
Stop an owned capture child, escalating only after its grace period.
- Parameters
-
pid Owned positive child PID. [out] status Wait status, set if the child is reaped here.
- Returns
- One if ownership ended, zero if still waiting after escalation, or -1 on error.
Reap an already exited child first. Give normal teardown a chance to release the camera before sending SIGKILL.
Definition at line 140 of file lwir_cam_pipe.c.
◆ wait_child()
|
static |
Wait up to a bounded time for the capture child to exit.
- Parameters
-
pid Owned positive child PID. [out] status Wait status, set if this call reaps the child. timeout_ms Nonnegative budget; zero checks without sleeping.
- Returns
- One if reaped or no longer a child, zero on timeout, or -1 on error.
Use nonblocking waits so a child stuck in a device call does not indefinitely block its supervisor.
Definition at line 119 of file lwir_cam_pipe.c.
Variable Documentation
◆ calibration_path
|
static |
Definition at line 84 of file lwir_cam_pipe.c.
◆ capture_command
|
static |
Definition at line 86 of file lwir_cam_pipe.c.
◆ capture_delay_s
|
static |
Definition at line 81 of file lwir_cam_pipe.c.
◆ capture_server_input
|
static |
Definition at line 74 of file lwir_cam_pipe.c.
◆ capture_server_output
|
static |
Definition at line 75 of file lwir_cam_pipe.c.
◆ capture_server_pid
|
static |
Definition at line 73 of file lwir_cam_pipe.c.
◆ capture_times
|
static |
Definition at line 82 of file lwir_cam_pipe.c.
◆ environ
|
extern |
◆ lwir_config
|
static |
Definition at line 87 of file lwir_cam_pipe.c.
◆ native_raw_enabled
|
static |
Definition at line 83 of file lwir_cam_pipe.c.
◆ photo_directory
|
static |
Definition at line 85 of file lwir_cam_pipe.c.
◆ running
|
static |
Definition at line 88 of file lwir_cam_pipe.c.
◆ status_buffer
|
static |
Buffered reassembly for read_server_status(): avoids one poll()+read() syscall pair per byte, which otherwise adds up to hundreds of syscalls per response line set on every single shot.
Definition at line 79 of file lwir_cam_pipe.c.
◆ status_buffer_pos
|
static |
Definition at line 80 of file lwir_cam_pipe.c.
◆ status_buffer_size
|
static |
Definition at line 80 of file lwir_cam_pipe.c.