
Loading...
Searching...
No Matches
dipla_planner.cpp File Reference
Turn a synthetic survey's GP belief into eight model or comparison points. More...
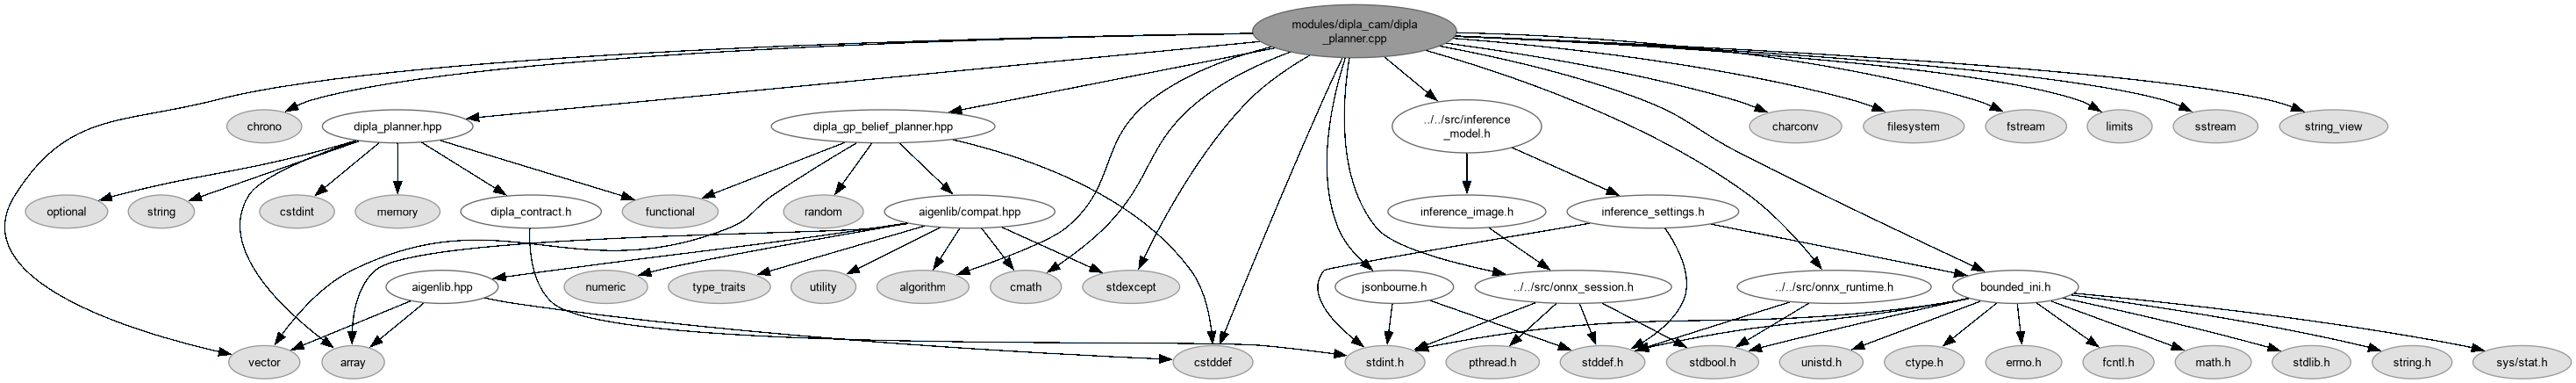
#include "dipla_planner.hpp"#include <chrono>#include "dipla_gp_belief_planner.hpp"#include <jsonbourne.h>#include "../../src/onnx_runtime.h"#include "../../src/onnx_session.h"#include "../../src/inference_model.h"#include "../../src/bounded_ini.h"#include <algorithm>#include <charconv>#include <cmath>#include <cstddef>#include <filesystem>#include <fstream>#include <limits>#include <sstream>#include <stdexcept>#include <string_view>#include <vector>
Include dependency graph for dipla_planner.cpp:
Go to the source code of this file.
Data Structures | |
| struct | dipla::Network::State |
| Runtime-owned ONNX session and reusable input/output storage. More... | |
| struct | dipla::Network::State::ConditioningCache |
| Own the paired encoder and cached denoiser plus their bound tensors. More... | |
| struct | dipla::Survey::State |
| Private storage for the synthetic field and its GP posterior. More... | |
Namespaces | |
| namespace | dipla |
Functions | |
| void | dipla::initialize_runtime (const std::string &onnx_lib_path={}) |
| Load the ONNX Runtime C API before constructing an inference session. | |
| void | dipla::apply_flight_margin (Waypoints &route, unsigned margin_cells=ExperimentOptions::default_margin_cells) |
| Apply the configured horizontal flight margin. | |
Detailed Description
Turn a synthetic survey's GP belief into eight model or comparison points.
Three responsibilities deliberately meet here without becoming one algorithm:
- Survey owns the hidden field and Gaussian-process (GP) posterior. Only a sensor footprint may reveal truth; planners receive the resulting belief.
- Network adapts that belief to the exported ONNX denoiser and performs the complete deterministic DDIM reverse process, returning raw XYZ in metres.
- apply_flight_margin() prepares either planner's route for publication, without changing the sampler's numerically testable model contract.
The flight controller, not this file, decides when a route has been flown. Keeping inference, flight preparation, and mission progress separate lets us compare the sampler with the Python reference without importing flight policy into the maths. There is one neural network here, not a second flight network.
- When adapting a model
- Grid geometry, axis order, world scaling, tensor bindings, normalizations, and the diffusion schedule form one contract. Update and test them together; a tensor with the right shape can still describe entirely the wrong world.
- Warning
- Reused network tensors and mutable survey state require serialized ownership. Fixed tensor buffers do not make ONNX Runtime or the GP heap-free; the dense covariance alone occupies about 51.6 MiB.
- See also
- dipla_planner.hpp Public ownership, input, and result contracts.
Definition in file dipla_planner.cpp.