
Optional thermal candidate detection, independent of pose and image files. More...
#include "lwir_frame.h"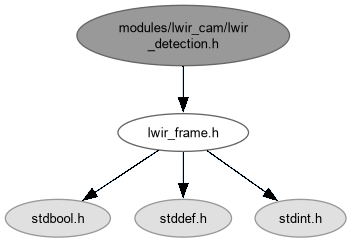
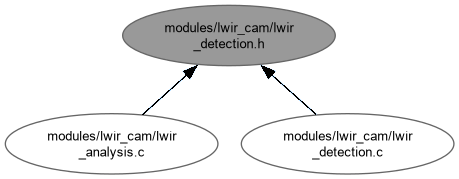
Go to the source code of this file.
Data Structures | |
| struct | lwir_hotspot |
| A thermal component expressed only in native sensor coordinates. More... | |
| struct | lwir_hotspot_set |
| Bounded ranking, retaining the existing two-candidate mission policy. More... | |
| struct | lwir_detection_workspace |
| Caller-owned scratch storage; never reserved by an imagery-only build. More... | |
Functions | |
| bool | lwir_detect_hotspots (const uint8_t *temperature, size_t bytes, unsigned width, unsigned height, struct lwir_detection_workspace *workspace, struct lwir_hotspot_set *result) |
| Rank native thermal components without touching hardware, pose or files. | |
Detailed Description
Optional thermal candidate detection, independent of pose and image files.
Compiled only in analysis builds (LWIR_ENABLE_ANALYSIS=1). Input is the exact native Kelvin*64 temperature plane embedded in a saved LWIR JPEG, never the compressed display pixels, so thresholds operate on sensor values. The detector does no I/O, uses no heap, and keeps all scratch storage in a caller-provided lwir_detection_workspace. lwir_analysis.c is the in-tree caller.
Definition in file lwir_detection.h.
Function Documentation
◆ lwir_detect_hotspots()
| bool lwir_detect_hotspots | ( | const uint8_t * | temperature, |
| size_t | bytes, | ||
| unsigned | width, | ||
| unsigned | height, | ||
| struct lwir_detection_workspace * | workspace, | ||
| struct lwir_hotspot_set * | result ) |
Rank native thermal components without touching hardware, pose or files.
- Parameters
-
temperature Immutable little-endian Kelvin*64 plane. bytes Exact accessible plane length, width * height * 2. width Native width, at most LWIR_MAX_WIDTH. height Native height, at most LWIR_MAX_HEIGHT. workspace Exclusive scratch storage for this call, separate from input/result. result Bounded candidates; ignore on failure.
- Returns
- True for a valid plane, including a plane with no candidates or no valid codes at all (then background_celsius and threshold_celsius are NaN). False for NULL pointers, zero or oversized dimensions, or a length mismatch.
Threshold = max(60 C absolute, frame median + max(20 C, 6 robust sigma)), where robust sigma is 1.4826 x the median absolute deviation. Pixels at or above it form 8-connected components; each must exceed its local background by at least 15 C. See lwir_detection.c for the full algorithm. Endpoint codes 0 and 65535 are invalid samples: they are excluded from the frame median, noise estimate, components and local backgrounds.
- Note
- Temperatures are apparent sensor values without emissivity or atmospheric correction; the 60/100 C limits apply to those values.
Rank native thermal components without touching hardware, pose or files.
See lwir_detection.h for the contract and the file overview for the algorithm. All arithmetic stays in raw Kelvin*64 codes until results are converted to Celsius (code / 64 - 273.15); temperature differences convert by dividing by 64 only.
- Returns
- True for a valid plane (even with zero candidates); false for invalid arguments.
Definition at line 172 of file lwir_detection.c.